corebrum-synapse
Health Gecti
- License — License: Apache-2.0
- Description — Repository has a description
- Active repo — Last push 0 days ago
- Community trust — 179 GitHub stars
Code Gecti
- Code scan — Scanned 12 files during light audit, no dangerous patterns found
Permissions Gecti
- Permissions — No dangerous permissions requested
Bu listing icin henuz AI raporu yok.
ROS plugin for OpenClaw, Claude (Code,Desktop,Dispatch), Codex, Google Gemini, Hermes, MCP, etc.
Corebrum Synapse
This project was previously known as AgenticROS.
This project was previously known as Corebrum Synapse.
    _                     _   _       ____   ___  ____
   / \   __ _  ___ _ __ | |_(_) ___ |  _ \ / _ \/ ___|
  / _ \ / _` |/ _ \ '_ \| __| |/ __|| |_) | | | \___ \
 / ___ \ (_| |  __/ | | | |_| | (__ |  _ <| |_| |___) |
/_/   \_\__, |\___|_| |_|\__|_|\___||_| \_\___/|____/
        |___/
  Corebrum Synapse - agentic AI for ROS-powered robots
Physical AI Agents for ROS Robots
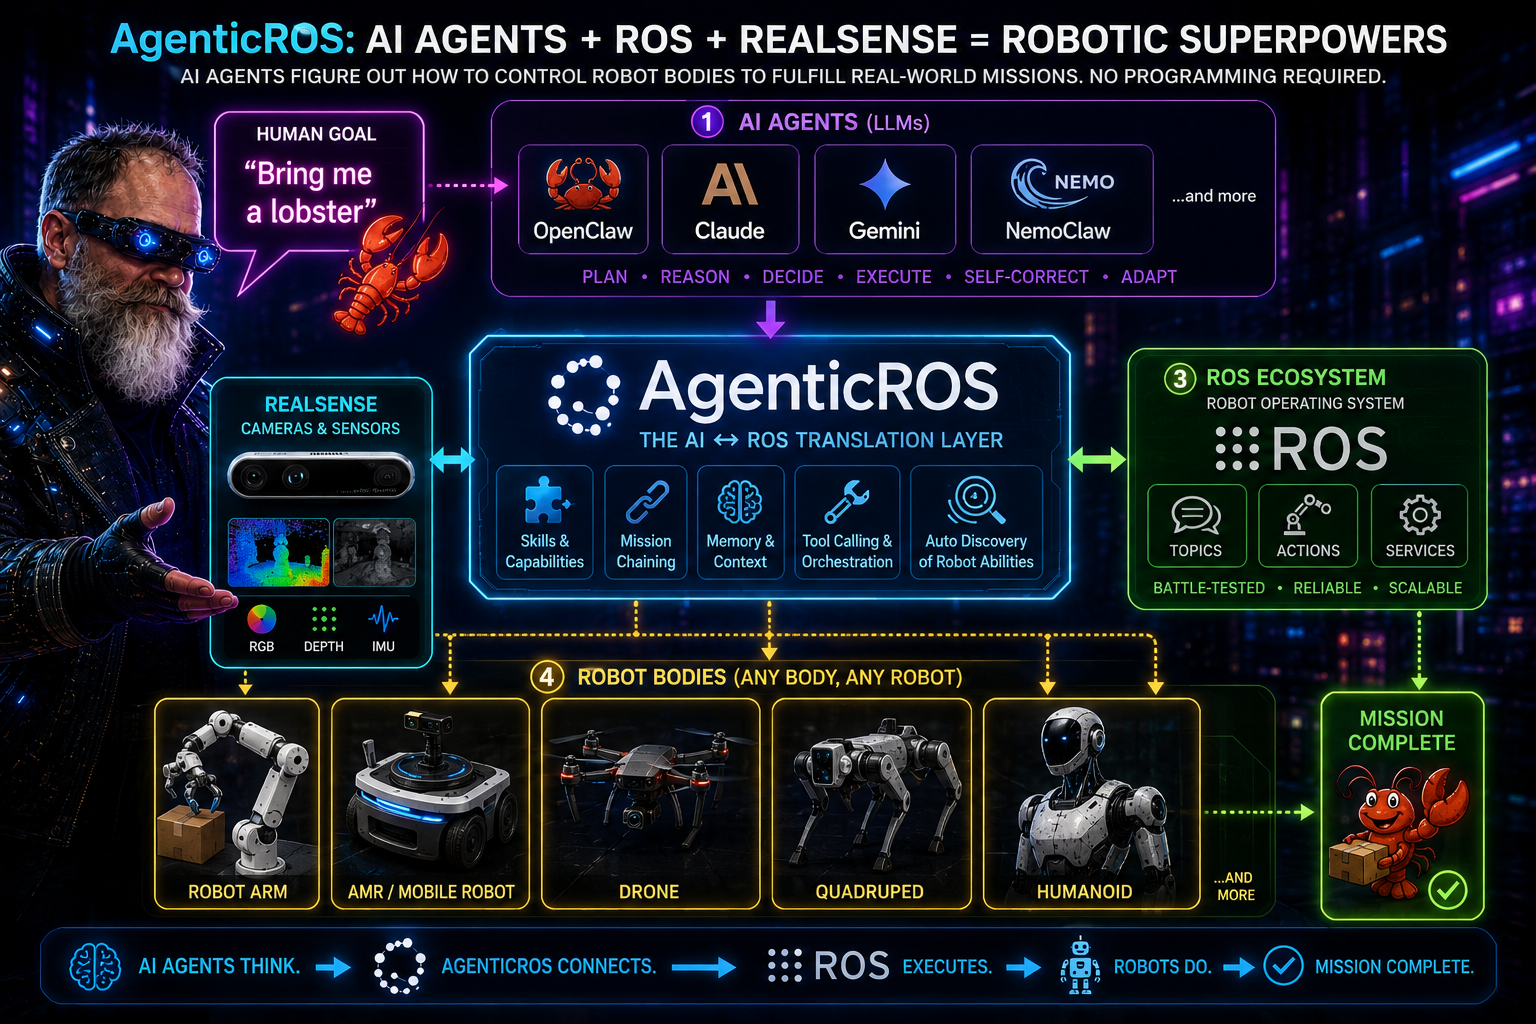
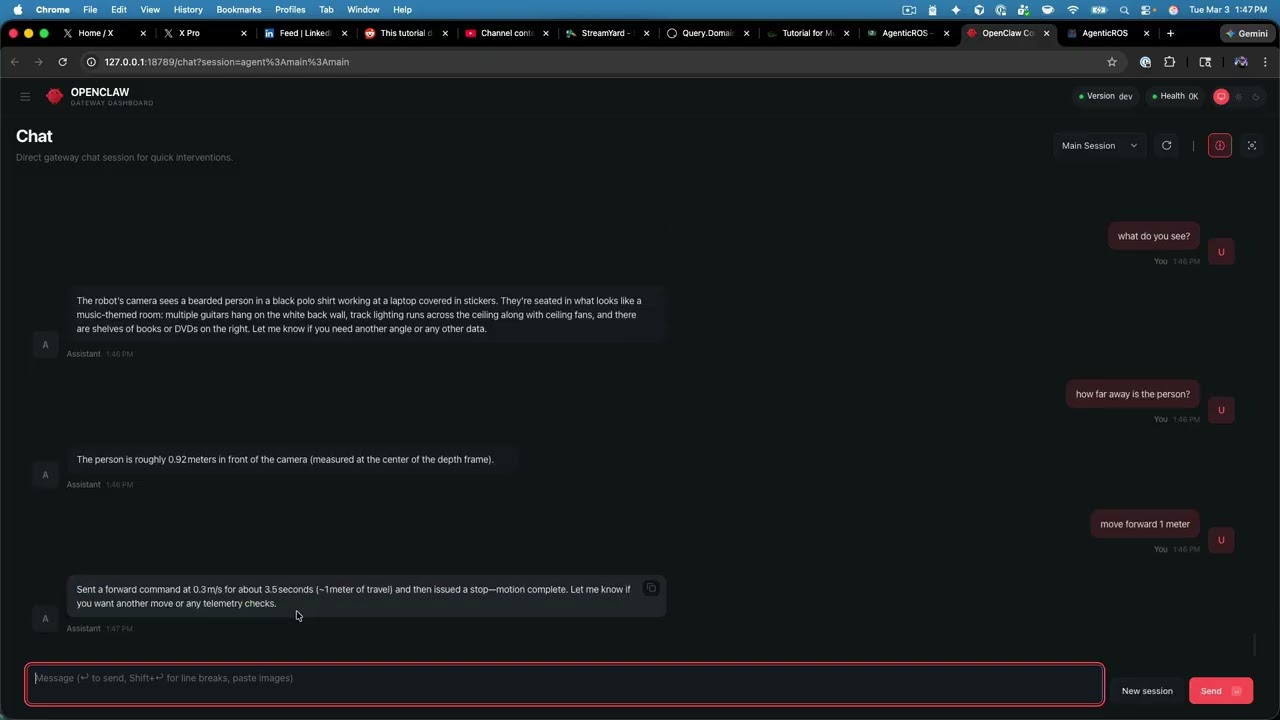
Corebrum Synapse turns ROS 2 robots into agent-native machines. Speak, type, or message — and your robot perceives, reasons, and acts. It is an open, AI-agent-agnostic interface layer that bridges the world of frontier reasoning models with the world of cameras, depth sensors, motors, and cmd_vel, so robots stop being remote-controlled tools and start collaborating like teammates.
With Corebrum Synapse, your robot can describe what it sees, follow intent ("go check the front door"), run skills you author, and respond to natural language across the agent platforms you already use. One ROS 2 workspace, one config, many agents.
Building a robot from parts? Start with the hardware getting started guide — reference BOM (Jetson or Pi / RADXA / LattePanda / x86+Arduino), L298N GPIO wiring for /cmd_vel and /odom, RealSense, then OpenClaw and other agents.
Supported AI Agent platforms
- OpenClaw — Native gateway plugin with ROS 2 tools, commands, a config UI, a teleop web app, and a skill loader. The flagship integration.
- NVIDIA NemoClaw — Run Corebrum Synapse inside NemoClaw's OpenShell sandbox with policy-enforced egress and managed NVIDIA inference; ROS 2, RealSense, and rosbridge stay on the host while the plugin runs sandboxed.
- Anthropic Claude — A single MCP server powers Claude Code (terminal), Claude Desktop (macOS / Windows), and Claude Dispatch (iOS, paired to your Mac). Ask Claude what your robot sees, and it answers with a live camera snapshot and depth reading.
- OpenAI Codex CLI — Same MCP server as Claude Code. One command registers Codex:
synapse codex setup(writes~/.codex/config.tomlwith an absolute path to the MCP binary). Full tool surface: missions, follow-me, find-object, memory. Setup guide: docs/codex-setup.md. - Hermes Agent — Model-agnostic agent gateway (OpenRouter, Ollama, 200+ providers) with MCP client support. Same MCP server as Codex:
synapse hermes setupwrites~/.hermes/config.yaml. Setup guide: docs/hermes-setup.md. - Google Antigravity CLI (
agy) — Same MCP server, using your Antigravity subscription (noGEMINI_API_KEY).synapse agy setupwrites~/.gemini/config/mcp_config.jsonand installs the Corebrum Synapse skill. Run a prompt withsynapse agy run. Setup guide: docs/agy-setup.md. - Google Gemini — Standalone CLI that uses Gemini function calling against the same ROS 2 tools (no MCP required) — ideal for scripting and headless agents. This path needs
GEMINI_API_KEY. Antigravity CLI is the subscription path above.
Corebrum Synapse is built so that new adapters (LangGraph, OpenAI, local models, voice stacks, etc.) can be added without touching the ROS 2 layer. The core transport and tool contract are platform-agnostic; adapters are thin shims that surface those tools to each agent runtime.
Local VLM (Ollama) — no cloud API required
Control your robot with a local vision-language model instead of OpenAI or other cloud APIs. Corebrum Synapse robot tools work the same; you point OpenClaw or Hermes at Ollama on your machine.
ollama pull qwen3-vl:8b-instruct   # recommended: chat + tools + camera vision
# or: ollama pull qwen3-vl:2b     # smaller hardware

npx @corebrum/synapse init               # skip the OpenAI key step when prompted
# Configure OpenClaw to use Ollama as primary model (see guide below)
synapse up sim-amr             # or: synapse up real
Then chat in OpenClaw web UI or Hermes: "List ROS topics", "drive forward slowly", "what do you see?"
| Path | Best for |
|---|---|
| OpenClaw + Ollama | Web chat, teleop, messaging channels, skills |
| Hermes + Ollama | Terminal agent with any Ollama model |
| NemoClaw + Ollama | Sandboxed Jetson / edge (see docs/nemoclaw.md) |
Full setup, model picks, multimodal catalog patches, describer, Follow Me VLM, and troubleshooting: docs/local-vlm.md
Architecture
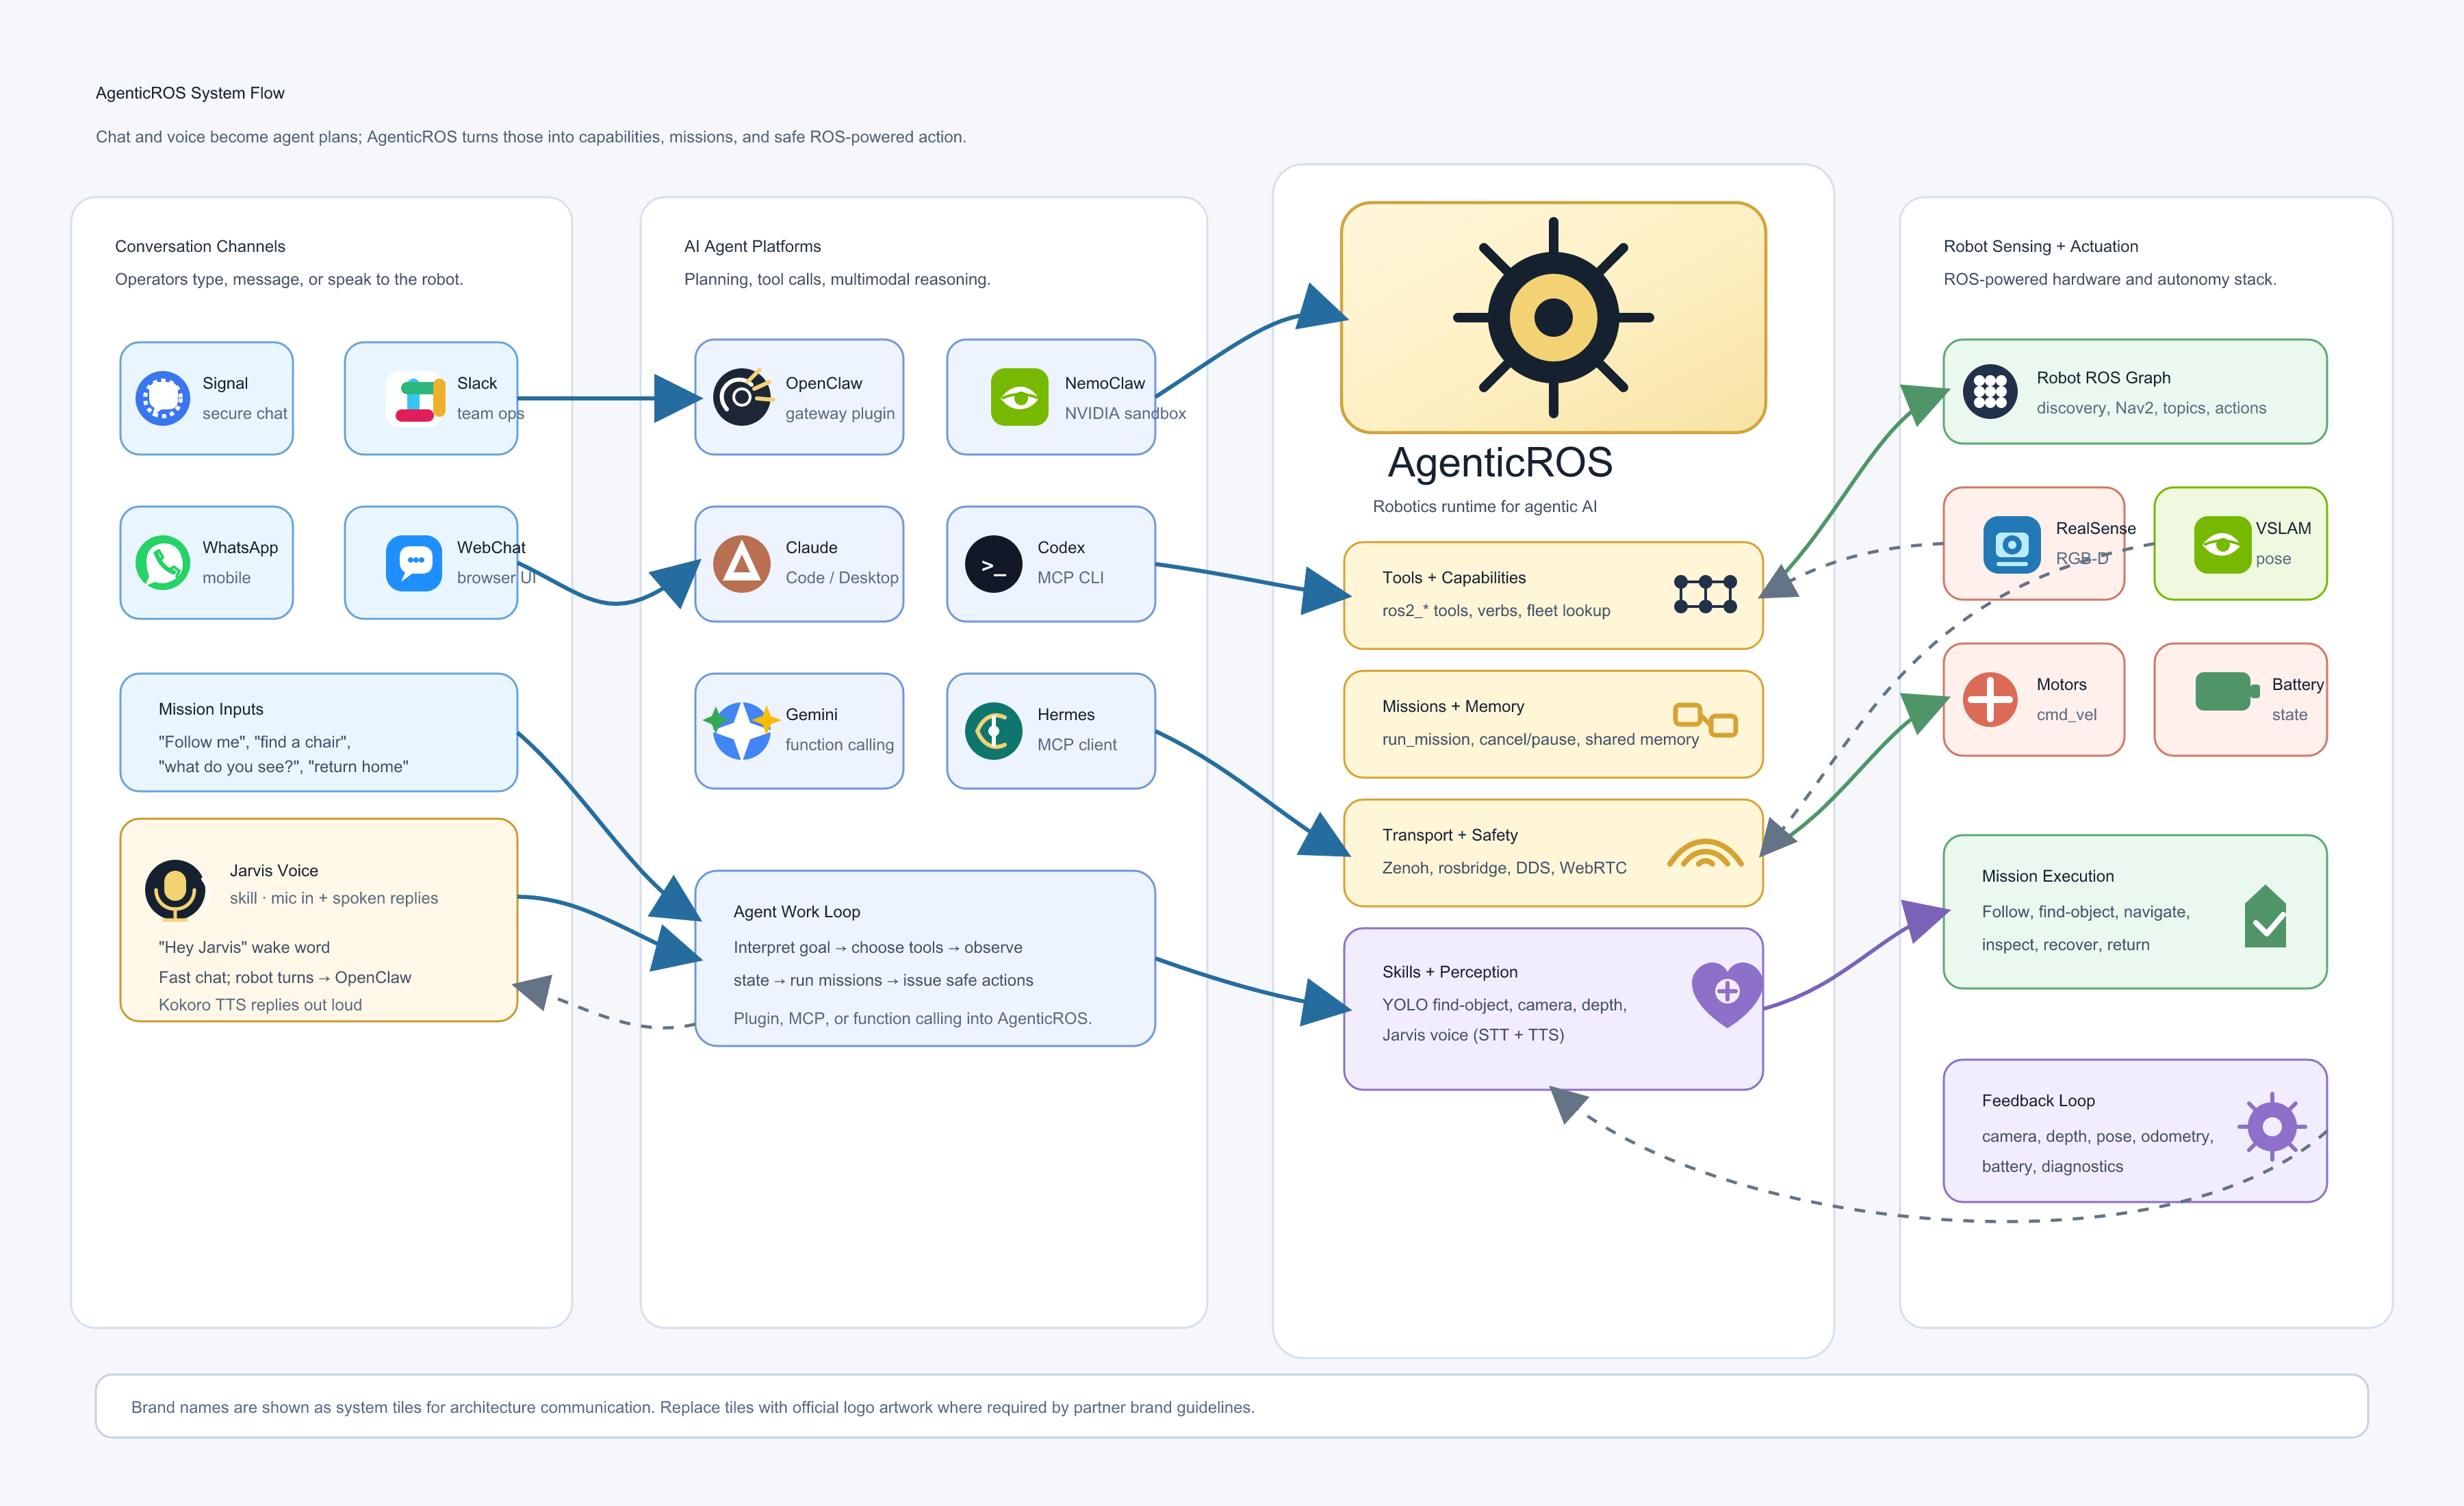
- Core (
packages/core): Platform-agnostic ROS2 transport (Zenoh, rosbridge, local DDS, WebRTC), capability/mission runtime, shared memory, config schema, and types. No dependency on any specific AI platform. - Adapters: OpenClaw plugin (
packages/synapse-openclaw, including NemoClaw); MCP server (packages/synapse-claude-code) for Claude Code / Desktop / Dispatch, Codex CLI, Hermes Agent, and Antigravity CLI (agy); Gemini API CLI (packages/synapse-gemini) via function calling. See packages/synapse-claude-code/README.md, docs/codex-setup.md, docs/hermes-setup.md, and docs/agy-setup.md. - Perception:
@corebrum/ros-camera(Image / CompressedImage snapshots) and@corebrum/object-detection(YOLOv8n find-object), shared by every adapter.
User (messaging app) → OpenClaw Gateway → Corebrum Synapse OpenClaw plugin → Core → ROS2 robots
Claude (Code / desktop / Dispatch) → synapse MCP server → Core → ROS2 robots (Zenoh/rosbridge)
Codex CLI → synapse MCP server → Core → ROS2 robots (Zenoh/rosbridge)
Hermes Agent → synapse MCP server → Core → ROS2 robots (Zenoh/rosbridge)
Antigravity CLI (agy) → synapse MCP server → Core → ROS2 robots (Zenoh/rosbridge)
Gemini CLI → @corebrum/gemini (function calling) → Core → ROS2 robots
A shared mission language for robots
The same tool surface across every adapter — Claude Code, Codex, Hermes, Antigravity CLI, Gemini, OpenClaw — so two different agents on two different stacks can both speak the same dialect when controlling the same robot. Built around five capabilities.
Capability manifests — robots advertise verbs
Every Corebrum Synapse-enabled robot exposes a typed list of named verbs through ros2_list_capabilities: drive_base, take_snapshot, measure_depth, find_object, follow_person, plus whatever a skill package contributes. The agent plans against the verbs instead of raw ROS 2 topics — and the manifest is shaped to double as an ACP / A2A agent card.
Mission chaining — run_mission
One MCP tool, run_mission, executes a declarative step graph. Each step is { id, capability, inputs, on_fail }. Outputs from any step flow into later steps via {{stepId.outputs.field}} template references — so a detection wires straight into the next motion command with no glue code:
{
  "steps": [
    { "id": "find",     "capability": "find_object", "inputs": { "target": "chair" } },
    { "id": "approach", "capability": "drive_base",
      "inputs": {
        "linear_x": 0.2,
        "angular_z": "{{find.outputs.horizontal_offset}}"
      }
    }
  ]
}
Natural-language goals
run_mission also accepts a goal field — plain English. A rule-based, deterministic planner in @corebrum/core compiles it into a runnable mission against the robot's capability registry:
"take a picture"→take_snapshot"follow me"→follow_person"drive forward at 0.3 m/s"→drive_base { linear_x: 0.3 }"find a chair and drive toward it"→ the two-step compound plan above
No LLM dependency (the planner is a few hundred lines of pattern matching, so the runtime doesn't require Ollama) and no fabricated calls (it only emits capabilities actually in the registry). Uncompilable goals return a clean error with the recognised-verb list so the agent can self-correct.
Multi-robot fleets
ros2_list_robots, ros2_discover_robots, and ros2_find_robots_for({ capability, kind?, online? }) let an agent ask "give me an AMR that can follow_person and is currently online" and get back a ranked list. The CLI keeps fleet metadata in sync without hand-editing JSON:
synapse robots add my-amr \
  --kind=amr --sensors=has_realsense,!has_arm \
  --capabilities=drive_base,take_snapshot,follow_person
On the ROS side, every robot publishes a 1 Hz heartbeat on <ns>/synapse/robot_info so the online filter reflects what's actually reachable. A single mission can route different steps to different robots — "the AMR finds the box, the arm picks it up" runs as one mission.
Cancel + shared transcripts
mission_cancel({ mission_id }) flips an in-process cancellation token; the runner stops at the next step boundary and marks remaining steps cancelled. When the shared memory backend is on, every step is also written to mission:<id> in long-term memory, tagged with step:<status> and capability:<id>. A different agent — different process, different vendor — can memory_recall later and reconstruct exactly what happened, so two agents can collaborate on or hand off a mission.
How-to: step-by-step fleet setup, declarative plans, NL goals, cancel, and handoff — docs/missions.md. Runnable walkthrough: examples/find-and-approach/README.md.
Full architecture + design trade-offs: docs/strategy-ai-agents-plus-ros.md.
Repository layout
**packages/core**— Transport, types, config (Zod). Used by all adapters.**packages/synapse-openclaw**— OpenClaw plugin: tools, commands, config page, teleop routes.**packages/synapse-claude-code**— MCP server for Claude Code, Claude desktop / Dispatch, Codex, Hermes, and Antigravity CLI (tools only; no config UI).**packages/synapse-gemini**— Gemini API CLI (function calling; needsGEMINI_API_KEY). Separate from Antigravity CLI.**packages/robot-eyes**— On-robot face display (synapse eyes): animated eyes followcmd_velturns; when idle, follow a person in the RealSense camera if YOLO is already installed. Optional WASD. See docs/eyes.md.**ros2_ws/**— ROS2 workspace:synapse_msgs,synapse_bringup(Gazebo + RViz + rosbridge launches),synapse_discovery,synapse_agent,synapse_follow_me.**docs/**— Architecture, hardware getting started, skills, robot setup, Zenoh (npx zenoh-fleetfor Mode D fleets), teleop, eyes, local VLM / Ollama.**scripts/**— Workspace setup, gateway plugin config, run demos.**docker/**— Docker Compose and Dockerfiles for ROS2 + plugin images.**examples/**— Example projects.
Install
You only need one command. The synapse CLI handles everything else —
installing the ROS 2 workspace, building the MCP server, registering the
OpenClaw plugin, and wiring up your robot config.
npx @corebrum/synapse
That's it. Run it on any machine with Node ≥ 20, no git clone required.
If you are still wiring motors and a camera, do that first: docs/hardware.md.
The first run launches the interactive menu:
╔──────────────────────────────────────────────────╗
║  Corebrum Synapse - agentic AI for ROS-powered robots  ║
╚──────────────────────────────────────────────────╝

? What would you like to do?
  Launch with real robot
❯ Launch with simulation
  First-time setup (workspace + OpenClaw plugin + Codex MCP + optional API key)
  Manage skills (2 registered, 0 available, 0 broken)
  Stop everything
  Doctor (health check)
  Configure (API keys, namespace, transport)
  Tail logs
Pick First-time setup once (workspace + OpenClaw plugin + optional Codex MCP + optional API key, all
idempotent). Using local Ollama instead of OpenAI? Skip the API key step — see Local VLM (Ollama). Then choose how you want to run:
| You want to … | Pick |
|---|---|
| Drive your real robot (RealSense + motors + MCP) | Launch with real robot |
| Demo a simulated 2-wheel AMR in Gazebo + RViz | Launch with simulation → AMR |
| Demo a simulated 6-DOF arm (UR5e-shaped, per-joint position control) | Launch with simulation → 6-DOF arm |
Once a stack is up, point any of the supported agents — OpenClaw, Claude Code,
OpenAI Codex, Hermes Agent, Antigravity CLI, Claude Desktop / Dispatch, or Gemini CLI — at the same robot and start talking
to it. The CLI tracks what it spawned (pidfiles + logs under /tmp/synapse-*),
so Stop everything cleanly tears the demo down.
Prefer scripted invocations? Every menu item maps to a direct command:
npx @corebrum/synapse init             # one-time workspace + plugin + MCP clients (+ optional API key)
synapse mcp setup            # Codex, Hermes, Claude, and Antigravity
synapse codex setup          # register Corebrum Synapse MCP for OpenAI Codex CLI
synapse codex doctor         # validate ~/.codex/config.toml
synapse hermes setup         # register Corebrum Synapse MCP for Hermes Agent
synapse hermes doctor        # validate ~/.hermes/config.yaml
synapse agy setup            # register Corebrum Synapse MCP for Antigravity CLI
synapse agy doctor           # validate mcp_config.json + skill
synapse agy run "list topics"  # one prompt on your Antigravity subscription
synapse up real              # real robot stack
synapse up real --map        # real robot + RTAB-Map + Nav2
synapse up real --eyes       # real robot + on-display robot eyes
synapse up sim-amr           # simulated AMR (Gazebo + RViz, headless on Jetson)
synapse up sim-amr --nav2    # AMR + Nav2 for navigate_to missions
synapse up sim-arm           # simulated 6-DOF arm (per-joint /arm/*/cmd_pos)
synapse up sim-arm --moveit  # arm + MoveIt2 move_group + trajectory bridge
synapse skills install --bundle mapping   # start-slam + explore + navigate-to
synapse maps list                          # room maps on this robot
synapse maps create --label Kitchen --start
synapse maps use <id>                      # switch rooms and localize
synapse eyes                 # fullscreen robot eyes on a tablet / head unit
synapse mode <real|sim>      # swap the active config profile (namespace, transport)
synapse robots               # list / add / remove robots in the fleet (kind, sensors, capabilities)
synapse skills               # list / add / remove Corebrum Synapse skills (see below)
synapse doctor               # coloured health check
synapse down                 # stop everything we started
Full CLI reference: packages/synapse-cli/README.md.
Requirements
- Node.js ≥ 20 (the only hard requirement —
npx @corebrum/synapseinstalls pnpm
itself if missing) - ROS 2 Humble or Jazzy if you plan to use the real-robot stack or any
simulation (the CLI sources/opt/ros/<distro>/setup.bashand runscolcon buildfor you) - OpenClaw gateway only if you also want the OpenClaw web UI / chat /
teleop adapter
Contributing / building from source
Hacking on the packages themselves? Clone and use the local checkout — the CLI
auto-detects the workspace and uses live sources instead of the bundled snapshot:
git clone https://github.com/PlaiPin/synapse && cd synapse
pnpm install && pnpm build
./synapse                    # repo-local CLI shim, same menu as `npx @corebrum/synapse`
For the OpenClaw plugin specifically, point the gateway at this repo'spackages/synapse-openclaw and configure under plugins.entries.synapse.config.
Recommended: OpenClaw 2026.3.11+ — routes work at
http://127.0.0.1:18789/plugins/synapse/
(config, teleop). For local dev without token auth:node scripts/setup-openclaw-local.cjs then restart the gateway. Older gateways
needing token auth: run node scripts/synapse-proxy.cjs 18790 and open
http://127.0.0.1:18790/plugins/synapse/.
See docs/openclaw-releases-and-plugin-routes.md
and docs/teleop.md.
See docs/ for robot setup, missions, skills, teleop, simulation internals, and Docker.
RViz2 and Gazebo (TurtleBot3 + rosbridge)
The package **synapse_bringup** provides launch files and an RViz2 config so you can run the same style of stack used in **examples/turtlebot-chat** and **docker/**: TurtleBot3 in Gazebo, **/scan**, **/cmd_vel**, and rosbridge on port 9090 for the Corebrum Synapse plugin.
Install (Ubuntu / ROS 2 Jazzy): sudo apt install ros-jazzy-turtlebot3-gazebo ros-jazzy-rviz2 ros-jazzy-rosbridge-suite (or rely on the Docker image, which already includes them). **colcon build does not install this** — if you see package 'turtlebot3_gazebo' not found, run the apt line above, then verify with ros2 pkg prefix turtlebot3_gazebo after sourcing /opt/ros/jazzy/setup.bash.
For namespaced cmd_vel (same robot.namespace as the plugin in OpenClaw), pass **robot_namespace:=<id>** to the Gazebo bringup launches, or see synapse_bringup README.
Build the workspace package (from **ros2_ws** after a full colcon build, or alone):
cd ros2_ws
source /opt/ros/jazzy/setup.bash
colcon build --packages-select synapse_bringup
source install/setup.bash
Commands (after source install/setup.bash):
| Goal | Command |
|---|---|
Rosbridge + Gazebo (headless-friendly; plugin uses ws://localhost:9090) |
ros2 launch synapse_bringup rosbridge_gazebo.launch.py |
| Gazebo + RViz on one machine (needs a display) | ros2 launch synapse_bringup turtlebot3_gazebo_rviz.launch.py |
| RViz only (simulation already running) | ros2 launch synapse_bringup rviz.launch.py use_sim_time:=true |
| Gazebo only (you start rosbridge yourself) | ros2 launch synapse_bringup gazebo_turtlebot3.launch.py |
Parameters: e.g. turtlebot3_model:=waffle, or rviz_config:=/path/to/custom.rviz for the RViz launch.
Mode A (local DDS) — OpenClaw and Gazebo on the same machine, plugin transport **local** (no rosbridge). Match **ROS_DOMAIN_ID** between the sim and the plugin (default **0**):
ros2 launch synapse_bringup mode_a_gazebo.launch.py
# With RViz: ros2 launch synapse_bringup mode_a_gazebo_rviz.launch.py
In the Corebrum Synapse config UI, set Transport mode to local and Domain ID to the same value as ros_domain_id (default 0). Then drive the robot with the usual tools (e.g. ros2_publish on /cmd_vel).
Docker (starts Gazebo + TurtleBot3 + rosbridge — typical for Mode B plugin on host → ws://localhost:9090):
cd docker
docker compose -f docker-compose.yml -f docker-compose.sim.yml up ros2
Then configure the Corebrum Synapse plugin with **ws://localhost:9090** as usual. The bundled RViz config is **turtlebot3_synapse.rviz** (fixed frame **odom**, LaserScan **/scan**, RobotModel from **/robot_description**). Adjust displays in RViz if your robot uses different topic names.
Details: ros2_ws/src/synapse_bringup/README.md.
Running Corebrum Synapse on NemoClaw
NVIDIA NemoClaw packages OpenClaw inside an OpenShell sandbox container with policy-enforced egress and managed inference. Corebrum Synapse plugs into that OpenClaw the same way it plugs into a "vanilla" gateway — with one twist: ROS 2, RealSense, and rosbridge run on the host, and only the Corebrum Synapse plugin runs inside the sandbox. The plugin reaches the host over the Docker bridge at host.docker.internal:9090.
Quick steps (sandbox named nemo, robot has namespace <NS>):
# 1. Build + pack the plugin so it works in the sandbox's offline-npm env
pnpm install && pnpm build
pnpm --filter @corebrum/synapse deploy --prod /tmp/synapse-deploy
rm -f /tmp/synapse-deploy/node_modules/.pnpm/node_modules/@corebrum/synapse

# 2. Copy it into the sandbox and chown to the sandbox user
CONTAINER=$(docker ps --format '{{.Names}}' | grep '^openshell-nemo-')
docker exec "$CONTAINER" rm -rf /sandbox/synapse && docker exec "$CONTAINER" mkdir -p /sandbox/synapse
docker cp /tmp/synapse-deploy/. "$CONTAINER:/sandbox/synapse/"
docker exec "$CONTAINER" chown -R sandbox:sandbox /sandbox/synapse

# 3. Register + configure the plugin inside the sandbox (HOME=/sandbox is required)
docker exec -u sandbox -e HOME=/sandbox "$CONTAINER" \
    openclaw plugins install -l /sandbox/synapse           # Ctrl-C once it starts logging "ROS2 transport status:"

# 4. Open the host's rosbridge port in NemoClaw policy
nemoclaw nemo policy-add --from-file scripts/synapse-rosbridge.policy.yaml --yes

# 5. Start RealSense + rosbridge on the host
./scripts/run_nemoclaw_host_stack.sh humble robot_namespace:=<NS> align_depth:=true

# 6. Restart the sandbox gateway, verify, and chat
nemoclaw nemo recover
./scripts/smoke_test_nemoclaw.sh        # 6 checks; exits 0 when all green
nemoclaw nemo dashboard-url
Full walkthrough, troubleshooting, and a "full-embed" alternative (ROS / RealSense baked into a custom sandbox image): docs/nemoclaw.md.
Claude + Corebrum Synapse (MCP)
The Corebrum Synapse MCP server (@corebrum/claude-code) drives the robot from Claude Code (terminal) or from the Claude desktop app on macOS (including Claude Dispatch on iPhone when paired to Claude on your Mac). OpenAI Codex CLI uses the same server — see Codex + Corebrum Synapse below. Claude clients use different config files than Codex (.mcp.json / claude_desktop_config.json vs .codex/config.toml).
Shared MCP setup (Claude and Codex):
- Build (from repo root):
pnpm install && pnpm build - Corebrum Synapse config:
~/.synapse/config.json— setzenoh.routerEndpoint,robot.namespace,robot.cameraTopic, etc. (see packages/synapse-claude-code/README.md). - Zenoh: For a laptop + robots fleet, run
npx zenoh-fleetthen start the generated hubzenohd. Or usescripts/zenohd-synapse.json5— see docs/zenoh-synapse.md.
Optional: override robot.namespace per MCP launch with env **SYNAPSE_ROBOT_NAMESPACE**. Prefer leaving it empty in MCP/Codex config so synapse mode real|sim drives the active profile (see docs/codex-setup.md).
Claude Code CLI (terminal)
- Register MCP (project scope, from repo root):
claude mcp add --transport stdio --scope project synapse -- node packages/synapse-claude-code/dist/index.js
Or add the server via .mcp.json in the repo. To avoid multiple MCP processes, run pnpm mcp:kill before starting a fresh claude session after rebuilding.
2. Run: claude — e.g. “List ROS2 topics”, “What do you see?”, “Publish a stop to cmd_vel.”
Claude desktop app + Dispatch (iOS)
Claude Code stores MCP in ~/.claude.json or project .mcp.json. The Claude desktop app uses a separate file:
- macOS:
~/Library/Application Support/Claude/claude_desktop_config.json - Windows:
%APPDATA%\Claude\claude_desktop_config.json
- Copy your synapse MCP entry from Claude Code /
.mcp.jsonintomcpServersinclaude_desktop_config.json. - Use an absolute path to
packages/synapse-claude-code/dist/index.js(the desktop app’s working directory is not your repo root, so relativenode packages/...paths will fail). - Fully quit the Claude desktop app (not just close the window) and reopen it. The synapse tools should appear in the desktop app and in Dispatch when your phone is paired to Claude on the Mac.
Example mcpServers entry (adjust the path and namespace to your machine):
{
  "mcpServers": {
    "synapse": {
      "command": "sh",
      "args": [
        "-c",
        "node /ABSOLUTE/PATH/TO/synapse/packages/synapse-claude-code/dist/index.js 2>>/tmp/synapse-mcp.log"
      ],
      "env": {
        "SYNAPSE_ROBOT_NAMESPACE": "robotYOUR_NAMESPACE_NO_DASHES"
      }
    }
  }
}
Full steps, permissions (mcp__synapse), and troubleshooting are in packages/synapse-claude-code/README.md.
Codex + Corebrum Synapse (MCP)
OpenAI Codex CLI is a standard MCP client — it uses the same @corebrum/claude-code server as Claude Code (missions, follow-me, find-object, memory, full ROS tool surface). No separate adapter package.
Quick setup
pnpm install && pnpm build          # or: npx @corebrum/synapse init
synapse codex setup              # ~/.codex/config.toml (global)
synapse codex setup --project    # .codex/config.toml in repo root
synapse codex doctor             # validate absolute MCP path + namespace policy
Start Codex in your project directory, run /mcp — you should see synapse connected with the full tool list. Then ask e.g. “List ROS2 topics” or “What do you see?”
Config files
| File | Scope |
|---|---|
~/.codex/config.toml |
Global — all Codex sessions |
<project>/.codex/config.toml |
Project — when Codex runs in that directory |
synapse codex setup writes an absolute path to packages/synapse-claude-code/dist/index.js (or the bundled MCP path after npx @corebrum/synapse init). Relative paths fail because Codex does not spawn MCP servers from the repo root.
Leave SYNAPSE_ROBOT_NAMESPACE = "" in the Codex env block so ~/.synapse/config.json and synapse mode real|sim drive the active robot (same policy as .mcp.json).
Manual registration
codex mcp add synapse -- node "$(pwd)/packages/synapse-claude-code/dist/index.js"
Use an absolute path if not run from the repo root.
Troubleshooting
/mcpdoes not list synapse → runsynapse codex setup; checksynapse codex doctor- Transport timeout → bring up Zenoh/rosbridge or run
synapse up sim-amr/synapse up real - Logs →
/tmp/synapse-mcp.log
Full guide: docs/codex-setup.md.
Hermes + Corebrum Synapse (MCP)
Hermes Agent is a model-agnostic MCP client — it uses the same @corebrum/claude-code server as Claude Code and Codex (missions, follow-me, find-object, memory, full ROS tool surface). No separate adapter package. Works with OpenRouter, Ollama, Anthropic, OpenAI, and 200+ other providers.
Quick setup
pnpm install && pnpm build          # or: npx @corebrum/synapse init
synapse hermes setup             # ~/.hermes/config.yaml
synapse hermes doctor            # validate absolute MCP path + namespace policy
In Hermes, run /reload-mcp or restart, then hermes mcp test synapse. Ask e.g. “List ROS2 topics” or “What do you see?”
Config file
| File | Scope |
|---|---|
~/.hermes/config.yaml |
Global — default Hermes profile |
synapse hermes setup writes an absolute path to the MCP server and leaves SYNAPSE_ROBOT_NAMESPACE: "" so synapse mode real|sim drives the active robot (same policy as Codex).
Troubleshooting
- MCP tools missing → run
synapse hermes setup;/reload-mcpin Hermes; checksynapse hermes doctor - Transport timeout → bring up Zenoh/rosbridge or run
synapse up sim-amr/synapse up real
Full guide: docs/hermes-setup.md.
Antigravity CLI + Corebrum Synapse (MCP)
Google Antigravity CLI (agy) is an MCP client. It uses the same @corebrum/claude-code server as Claude Code, Codex, and Hermes. Quota comes from the Antigravity subscription you sign in with. There is no GEMINI_API_KEY and no separate adapter package. The Gemini API CLI further down is a different path.
Quick setup
pnpm install && pnpm build          # or: npx @corebrum/synapse init
synapse agy setup                # ~/.gemini/config/mcp_config.json + skill
synapse agy doctor               # validate absolute MCP path, namespace, skill
Sign in once with interactive agy. In that session, /mcp should list synapse. Then:
synapse agy run "List ROS 2 topics"
synapse agy run --yes "Drive forward slowly, then stop"   # auto-approve tools
Config files
| File | Scope |
|---|---|
~/.gemini/config/mcp_config.json |
Global MCP servers |
<repo>/.agents/mcp_config.json |
Workspace MCP servers |
~/.gemini/antigravity-cli/skills/synapse/SKILL.md |
When to use the robot tools |
synapse agy setup writes an absolute path to the MCP server and leaves SYNAPSE_ROBOT_NAMESPACE empty so synapse mode real|sim drives the active robot.
Troubleshooting
/mcpdoes not list synapse → runsynapse agy setup; Antigravity readsmcp_config.jsonagy runasks you to authenticate → open interactiveagyonce on this machine- Transport timeout → bring up Zenoh/rosbridge or run
synapse up sim-amr/synapse up real
Full guide: docs/agy-setup.md.
Gemini CLI
Use Google Gemini to chat with your robot from the terminal (same ROS2 tools as Claude Code, no MCP).
- Build:
pnpm install && pnpm build - Config: Same as Claude Code —
~/.synapse/config.jsonwithzenoh.routerEndpoint,robot.namespace, etc. - Run: Set
GEMINI_API_KEY(orGOOGLE_API_KEY) and run:
GEMINI_API_KEY=xxx pnpm --filter @corebrum/gemini exec synapse-gemini "What do you see?"
See packages/synapse-gemini/README.md for details and tested command examples (camera snapshot/description, depth distance, forward Twist, and stop).
Memory (optional)
Corebrum Synapse can give every adapter a shared, persistent, cross-process long-term memory so facts you teach the robot from one agent are immediately available in the others — Claude Desktop, Claude Code, OpenAI Codex, Hermes Agent, Antigravity CLI, Gemini CLI, OpenClaw chat. Off by default. Two backends:
local— zero deps, JSON-on-disk at~/.synapse/memory.json, keyword + recency search. Enable with one config flag.mem0— semantic search via the pure-Nodemem0aipackage (pnpm add mem0ai); file-backed vector store at~/.mem0/vector_store.db(shared across all processes on the host, no server to run); embedder auto-detects Ollama (http://localhost:11434) →OPENAI_API_KEY→ clear error.
When enabled, every adapter exposes four tools — memory_remember, memory_recall, memory_forget, memory_status. OpenClaw chats additionally get a system-context section that lists recently-remembered facts and instructs the LLM to call memory_recall before answering personal-context questions like "what do I have for X?" or "what's my Y?".
Memory is namespaced by robot.namespace so adapters talking to the same robot share the same store. See docs/memory.md for ready-to-paste recipes, cross-process verification steps, and troubleshooting. OpenClaw users can also enable it from the web config UI at /synapse/config (Memory section).
Quickest path to try it (fully local, no API keys):
pnpm add mem0ai
ollama pull nomic-embed-text   # ~270 MB embedder model
Add { "memory": { "enabled": true, "backend": "mem0" } } to ~/.synapse/config.json (or the OpenClaw config UI). Restart the gateway / MCP client. Then ask Claude Desktop "remember that I have a RealSense D435i for eyes" and ask Codex or OpenClaw "what do I have for eyes?" — same fact, every agent.
Skills
Corebrum Synapse skills are optional packages that add tools and behaviors (e.g. follow_person, find_object, navigate_to). They load at OpenClaw gateway start from skillPackages, skillPaths, and skillRefs (marketplace / npm pins cached under ~/.synapse/skills-cache/). Browse and install from skills.corebrum.com, or scaffold and publish your own with the CLI.
That marketplace is robot skills only. Third-party Agent Skills (SKILL.md) live upstream: skills.sh/official (official maker catalogs) and Jetson Agent Skills for Jetson Device and BSP workflows.
Managing skills with the CLI
# Search + install (prefers npm @corebrum/* when advertised; else git clone)
npx @corebrum/synapse skills search follow
npx @corebrum/synapse skills install @corebrum/followme
npx @corebrum/synapse skills install chrismatthieu/followme

# Skip automatic OpenClaw gateway restart:
npx @corebrum/synapse skills install @corebrum/navigate-to --no-restart

synapse skills                       # list registered skills
synapse skills discover              # interactive picker over candidates on disk
synapse skills add <path-or-name>    # register a clone (path) or npm package
synapse skills remove <id-or-name>   # unregister
synapse skills sync                  # refresh contracts.tools (+ auto-restart)
Create and publish a new skill (npm name @corebrum/<slug>):
npx @corebrum/synapse create-skill my-skill --template robot
cd corebrum-skill-my-skill && npm install && npm run dev
npx @corebrum/synapse publish   # GitHub + marketplace + npm publish
Seed catalog (npm): @corebrum/followme, find, navigate-to, navigate-through-poses, detect-humans, start-slam, explore, follow-me-ros, moveit-pick, dock-to-charger.
What the CLI writes
~/.openclaw/openclaw.json→plugins.entries.synapse.config.skillPaths[],.skillPackages[], and.skillRefs[]~/.synapse/config.json→skillRefsfor MCP / Gemini- Plugin
contracts.toolsviascripts/sync-skill-tools.mjs(OpenClaw 2026+)
Per-skill behaviour lives under config.skills.<skillId>. See each skill's README.
Contract & writing your own skill
A skill is a Node package with an "synapse": { "id": "..." } block in package.json and a registerSkill(api, config, context) export from main. Scaffold with npx @corebrum/synapse create-skill, publish with npx @corebrum/synapse publish, install with npx @corebrum/synapse skills install @corebrum/<slug>. See docs/skills.md and @corebrum/followme (marketplace).
Missions support step retry, pause/resume, and mid-step cancel for interruptible capabilities — see docs/missions.md.
Strategy & vision
Where Corebrum Synapse is going next — beyond the shared mission language above, the roadmap covers turning capability manifests into agent cards on the wire (WebRTC / A2A so a robot can register itself as an agent in a mesh), an LLM-backed planner behind the existing compileGoalToMission contract, the skills.corebrum.com marketplace with declarative auto-fetch and in-agent installs, spatial memory, and cross-vendor agent collaboration via ACP / A2A: docs/strategy-ai-agents-plus-ros.md.
License
Apache-2.0
Yorumlar (0)
Yorum birakmak icin giris yap.
Yorum birakSonuc bulunamadi