dcc-mcp-speedtree
Health Uyari
- No license — Repository has no license file
- Description — Repository has a description
- Active repo — Last push 0 days ago
- Low visibility — Only 5 GitHub stars
Code Gecti
- Code scan — Scanned 12 files during light audit, no dangerous patterns found
Permissions Gecti
- Permissions — No dangerous permissions requested
Bu listing icin henuz AI raporu yok.
SpeedTree MCP adapter in source preview for AI agents to edit experimental native generator graphs, run the licensed Modeler CLI, and verify vegetation exports in the DCC-MCP ecosystem.
dcc-mcp-speedtree
Create and edit native SpeedTree generator graphs, regenerate them with the
licensed Modeler command-line exporter, and hand verified assets to another
DCC-MCP adapter. Graph authoring uses the observed SPM/STT file format and is
experimental; full live Modeler control is not yet available.
Part of the DCC-MCP host matrix
dcc-mcp-speedtree — SpeedTree adapter for DCC-MCP — edit experimental native
generator graphs, run the licensed Modeler CLI and verify vegetation exports.
It is one of 48 host adapters in the DCC-MCP catalog. Every adapter speaks the same
MCP protocol and builds on the same core runtime contract; each one exposes the tools
its own host needs on top of that.
This block is generated from the catalog entry indcc-mcp-catalog.yml.
Re-run the generator after changing the catalog.
Native node showcase
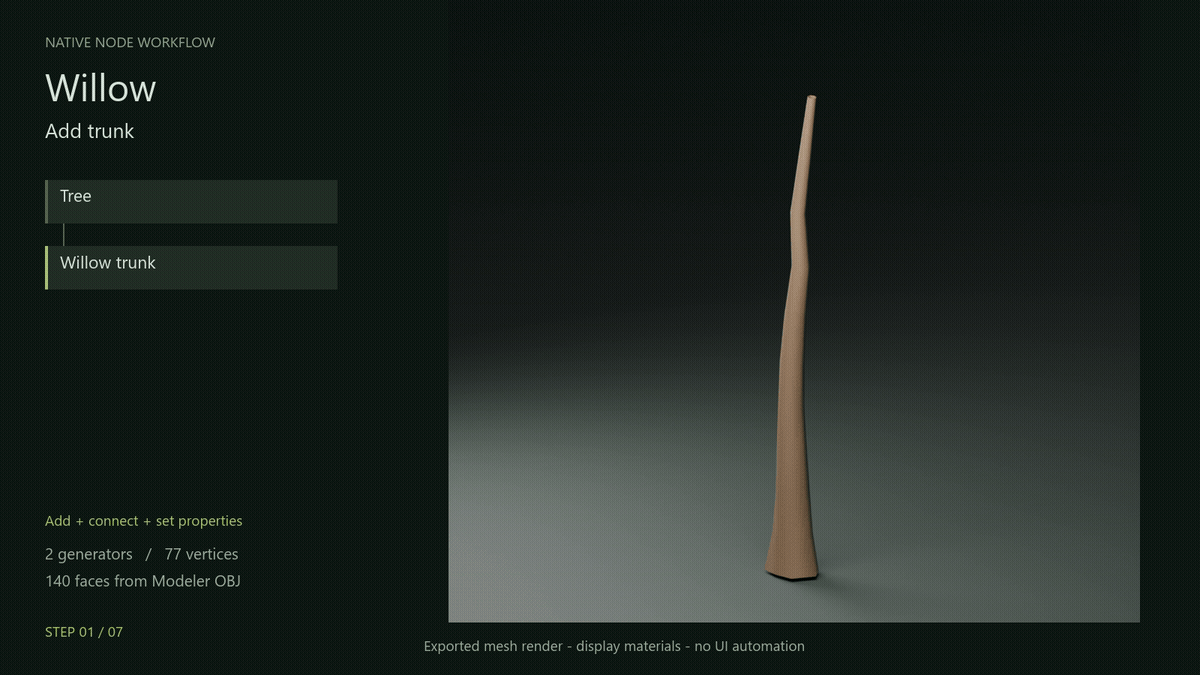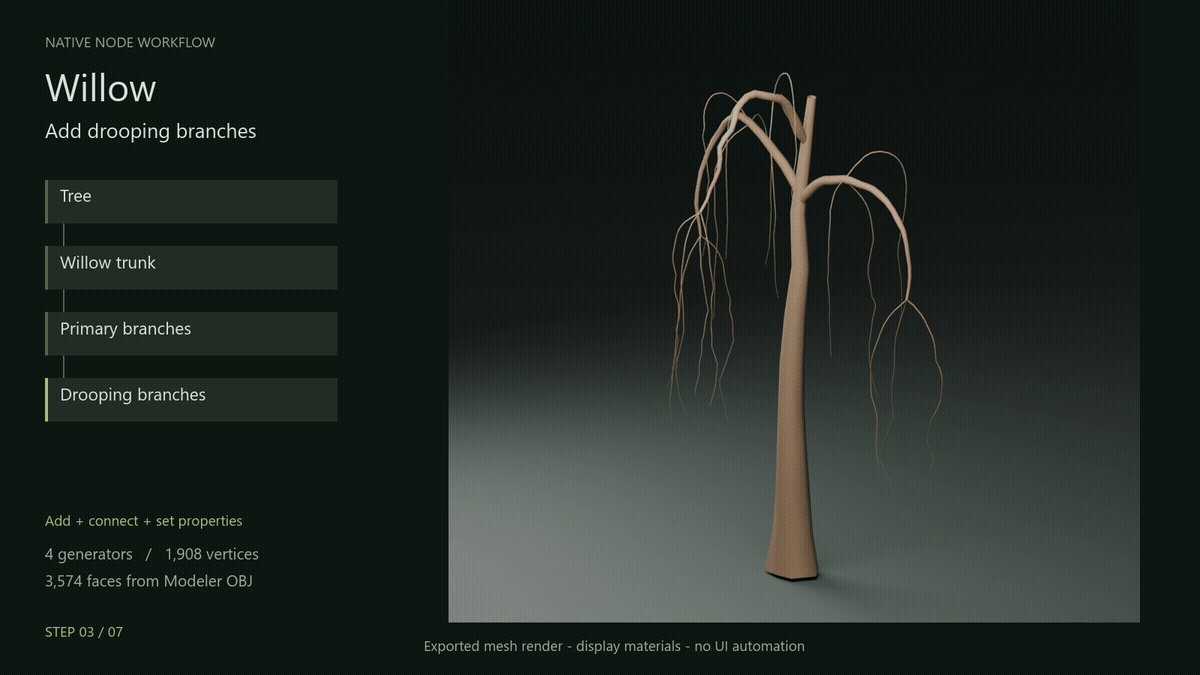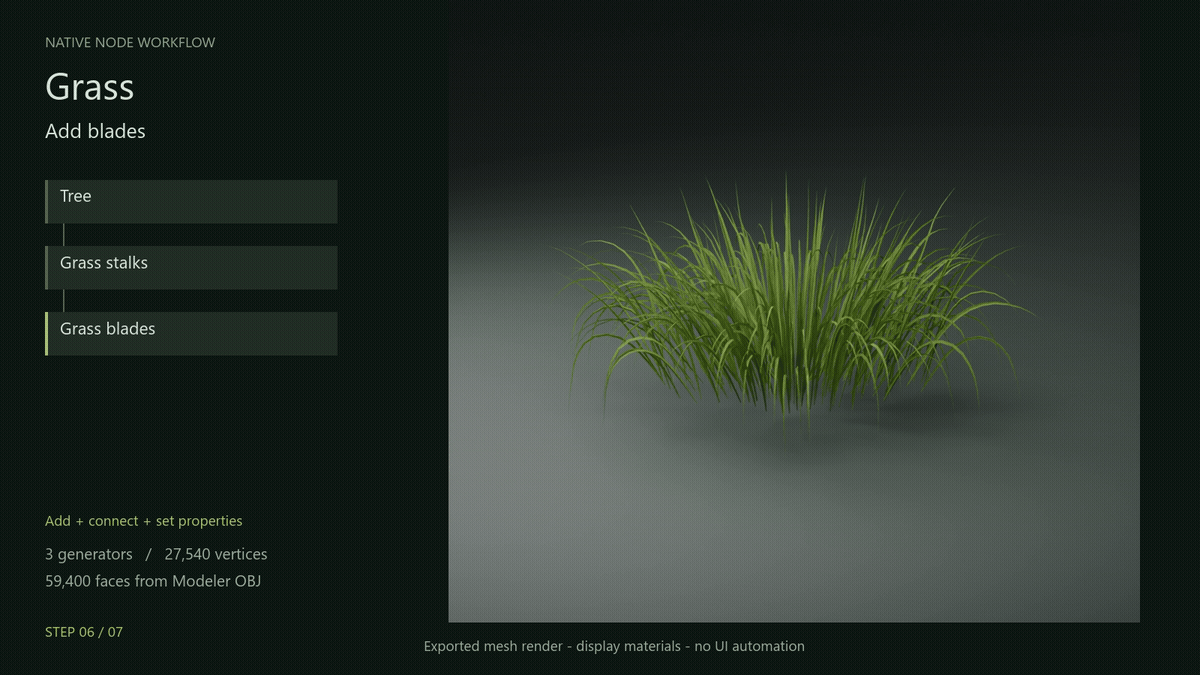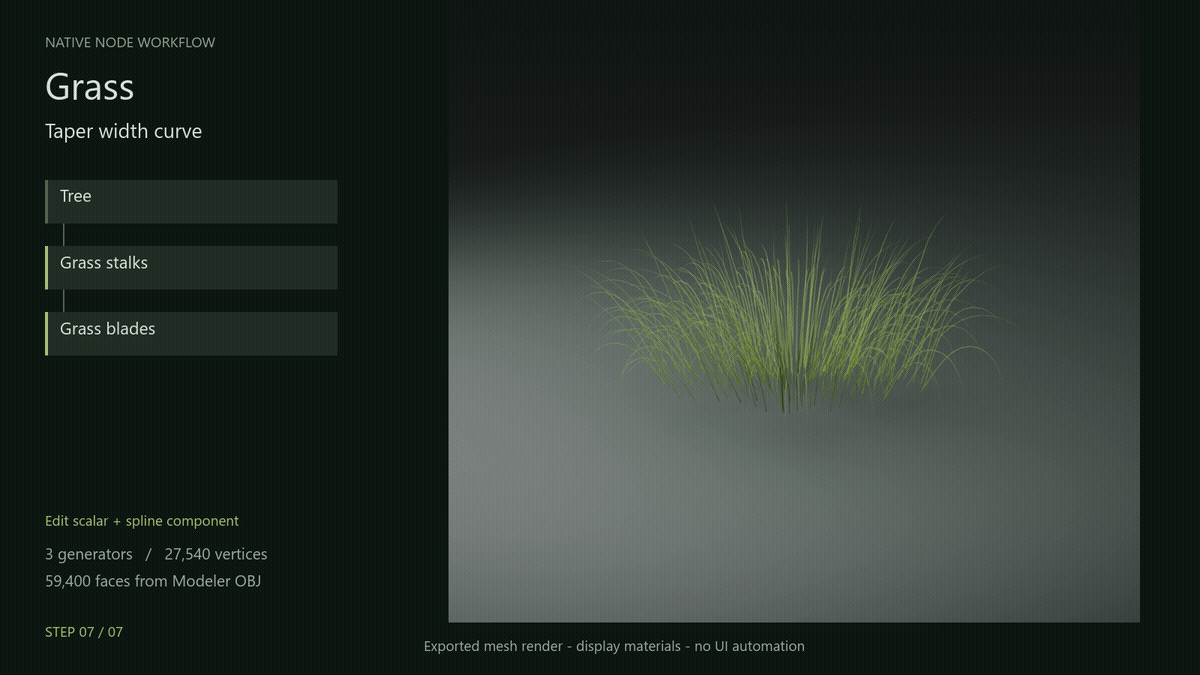
The willow grows from trunk to primary branches, drooping branches, and leaf
cards. The grass adds stalk and frond generators, then edits the width curve
to taper the blades. Each step is a new SPM, regenerated by SpeedTree Modeler
10.1.0. The diagram comes from the saved generator IDs and links.
| Native output | Generators | Vertices | Faces |
|---|---|---|---|
| Willow | 5 | 7,092 | 6,166 |
| Grass | 3 | 27,540 | 59,400 |
These are procedural geometry studies. The images use unchanged exported OBJ
geometry with display materials in headless Blender; they are not Modeler
screenshots or native material acceptance. No UI automation builds either
asset. Reproduce the workflow ·
Operation and geometry evidence ·
Native capability matrix.
Start
This is a source preview. Install the checkout with python -m pip install -e .,
then configure the installed Modeler executable:
$env:DCC_MCP_SPEEDTREE_EXECUTABLE = "C:/Applications/SpeedTree/SpeedTree_Modeler.exe"
dcc-mcp-speedtree
The standalone service has its own lifetime and OS-assigned port. Discover it
with dcc-mcp-cli --gateway local list, then search and describe its tools.
Optional GUI binding uses --pid <PID> --window-handle <HWND> and validates
that the window belongs to the named executable. GUI actions must use the
project-owned dcc-cua / ui-control route with a fresh exact binding.
Agent workflow
Read the capability audit for the complete tool chain
and the limits of modeling, materials, LOD, wind, collision, and cancellation.
Use inspect_capabilities for a machine-readable scope report without a GUI.
discover_templatesandinspect_authoring_catalogenumerate installed
generator templates and their stored properties.inspect_graphandinspect_propertiesread the selected source.edit_graphadds, duplicates,
removes, connects, disconnects, renames, hides, or changes properties and
existing curve components, writing a new SPM/STT.discover_contentlocates installed SPM samples and Games/VFX presets;inspect_presetreports the selected settings.plan_exportchecks an SPM, preset, format, and new output directory.export_batchexports 1–16 SPMs through-export_gameor-export, with-export_options. Supported extensions arest9,st,fbx,obj,abc, andusd; availability still depends on product version/license.export_statusreads progress while Core runs the job; Core cancellation
stops the owned export process (DELETE /v1/jobs/{id}on the owning service).verify_exportchecks the recorded file hashes before handoff. Each tree
lives in its own directory with its textures and material sidecar.plan_importprepares a verified handoff. Discover the destination adapter's importer, import into a new destination,
and read back geometry, materials, dependencies, transforms, and animation.
The asset bundle contract separates export evidence from
target import evidence. Format and target coverage
records the tested combinations and feature limits. The service never runs a
caller-supplied executable or shell command. Existing output directories are
rejected; timeout, failed exit, changed input, missing mesh, or missing explicit
material dependency stops the batch and preserves a partial manifest.
Unreal
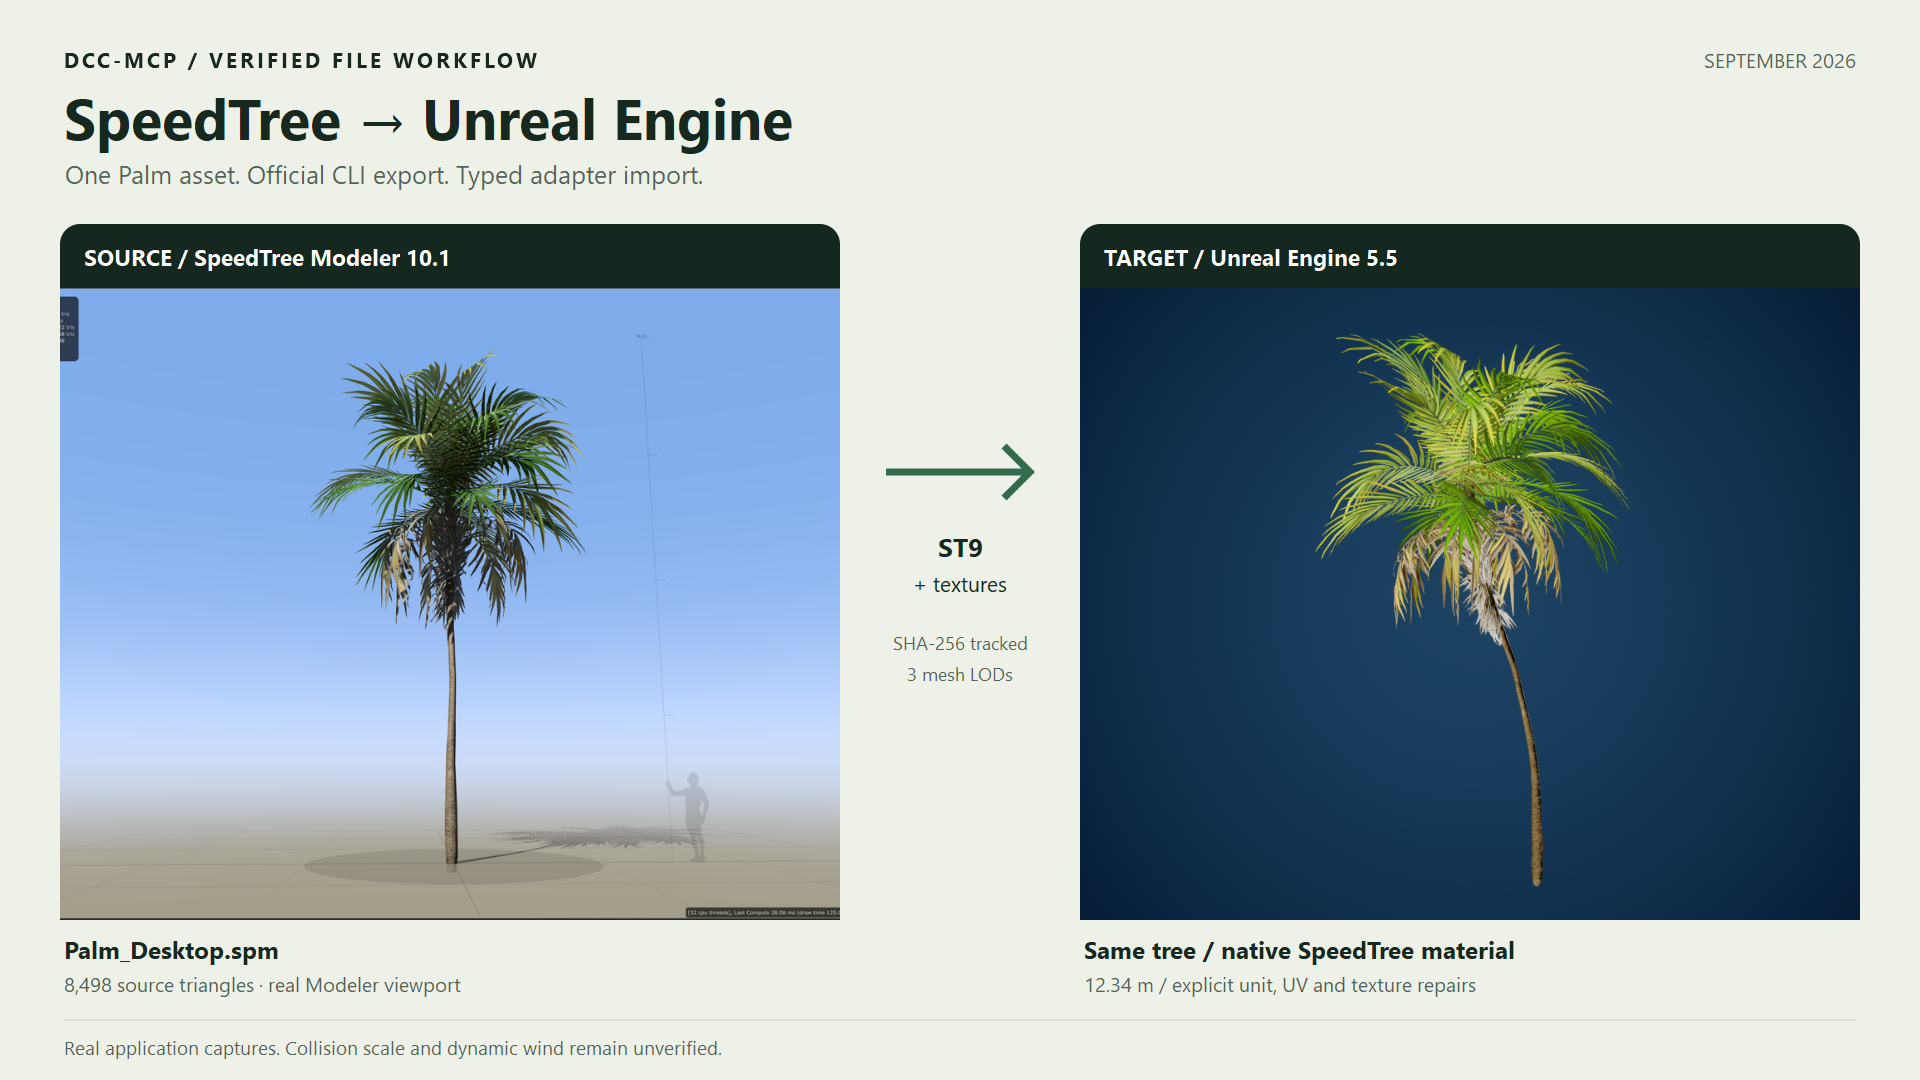
The same Palm asset in Modeler 10.1 and UE 5.5, using native SpeedTree
materials after explicit unit, UV, and texture repairs on a duplicate.
The final mesh height is 12.34384 m; collision scale and dynamic wind remain unverified.
Capture provenance and repair notes.
Use the installed Unreal ST9 Games preset for a modern Unreal workflow..spm is the authoring source, not a Content Browser import format.inspect_unreal_project reports descriptor entries only: a missing entry isnull because engine plugin defaults may enable it. Check installation and
loaded modules through dcc-mcp-unreal; configure missing plugins only after
the user authorizes the concrete plan. Configuration and restarts belong to
the target adapter. This service does not silently install or enable plugins.
After importing each ST9 via unreal-assets.import_asset, read back the mesh
and dependencies. Successful export or enabled plugins alone do not prove a
usable imported asset, correct wind, collision, or rendered appearance.
Official references
The repository contains no vendor binaries, licensed sample assets, SDK files,
or licensing material. Generated vendor sidecars can contain source-machine
paths; keep raw exports and diagnostics local unless reviewed for sharing.
Yorumlar (0)
Yorum birakmak icin giris yap.
Yorum birakSonuc bulunamadi