servomotor
Health Pass
- License — License: MIT
- Description — Repository has a description
- Active repo — Last push 0 days ago
- Community trust — 15 GitHub stars
Code Fail
- rm -rf — Recursive force deletion command in .github/workflows/publish-python.yml
Permissions Pass
- Permissions — No dangerous permissions requested
No AI report is available for this listing yet.
Open-source NEMA-17 integrated servomotor (motor + closed-loop driver + controller + encoder). RS-485, Python/Arduino libraries, MCP server for AI control. Hardware, firmware and software.
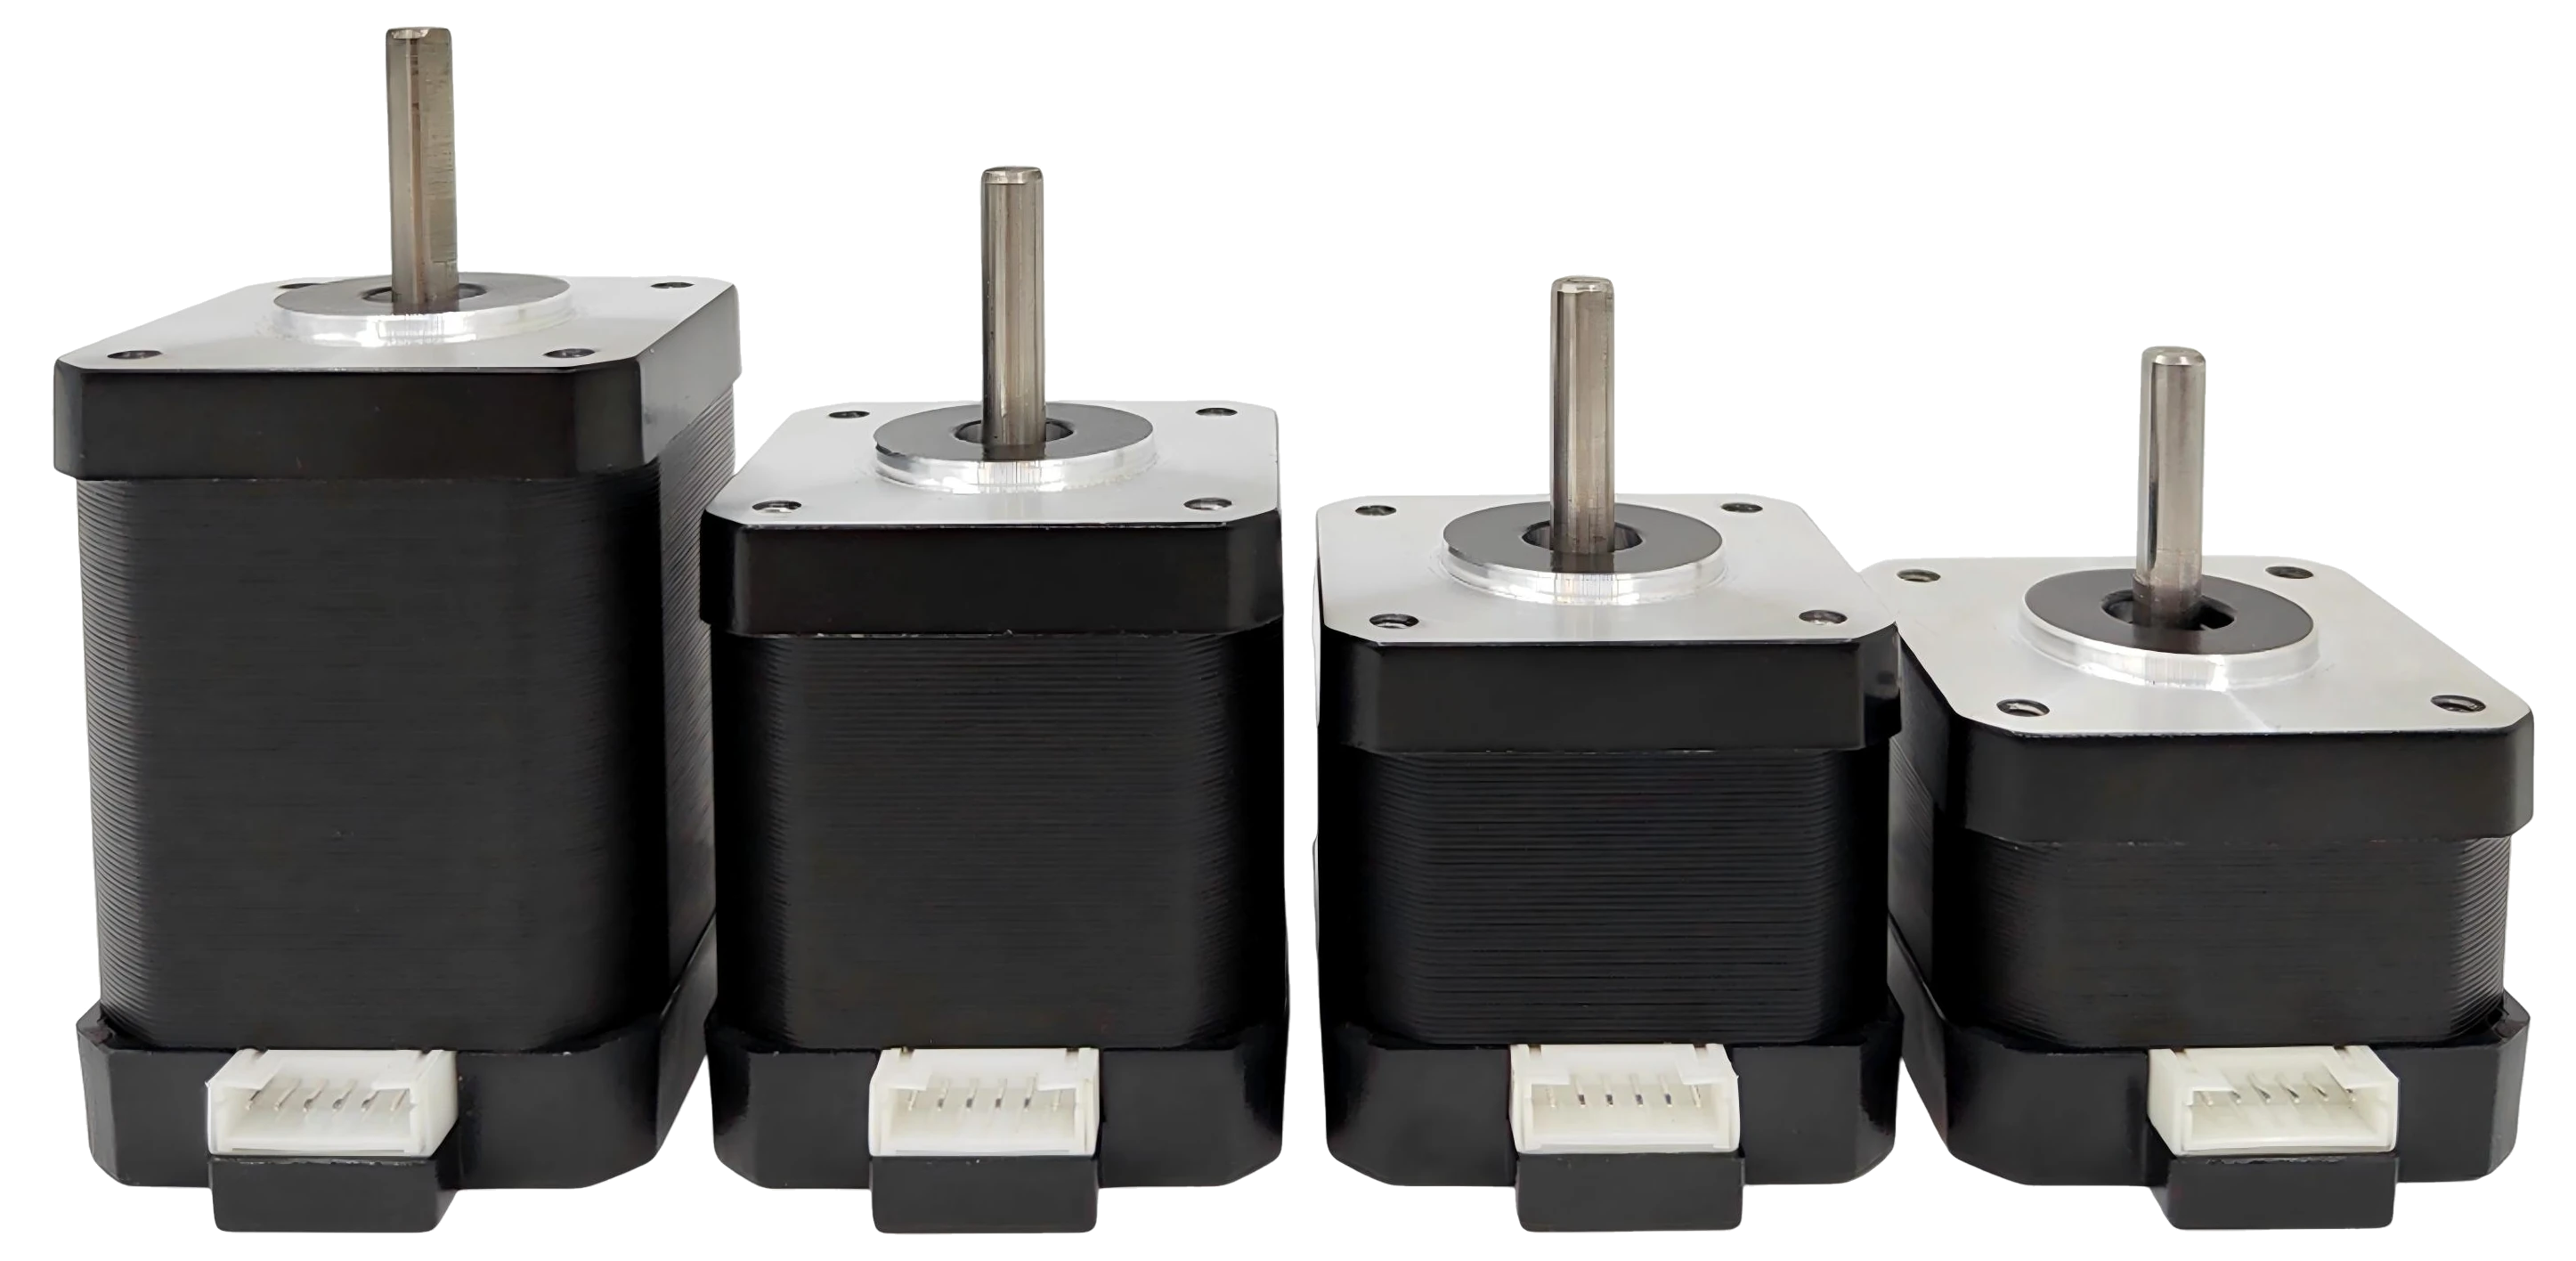
Gearotons M17 — an open-source servomotor you can talk to
The M17 is a NEMA-17 integrated servomotor: motor, closed-loop driver, motion controller and
magnetic encoder in one unit. It daisy-chains over RS-485, ships with Python and Arduino libraries,
and has a first-party MCP server so an AI assistant
(Claude Desktop, Claude Code, Cursor, …) can drive real motors from plain English.
Hardware, firmware and software are all in this repository under the MIT license.
| M17-34 | M17-40 | M17-48 | M17-60 | |
|---|---|---|---|---|
| Length | 33.5 mm | 40.1 mm | 48.7 mm | 59.7 mm |
| Holding torque | 0.28 N·m | 0.42 N·m | 0.55 N·m | 0.65 N·m |
| Weight | 210 g | 285 g | 360 g | 470 g |
All sizes: 12–24 V, up to ~1.1 A, up to 560 RPM, closed-loop 32 kHz control, RS-485 at 230400 baud,
64-bit unique ID + one-byte alias per motor, standard NEMA-17 mount. Indoor use (IP20).
Buy one: gearotons.com (from $20; ships worldwide from Shenzhen).
Documentation: 9o.at/M17_1.5 ·
Datasheet (PDF) ·
Python API ·
Arduino API
Quick start (Python)
pip install servomotor
import time, servomotor

servomotor.open_serial_port()                      # prompts for the USB–RS-485 adapter the first time
m = servomotor.M3("X", time_unit="seconds", position_unit="shaft_rotations")
m.enable_mosfets()
m.trapezoid_move(1.0, 1.0)                         # one full turn, in one second
time.sleep(1.1)
m.disable_mosfets()
servomotor.close_serial_port()
That is python_programs/example_trapezoid_move.py.
Units are yours to choose (degrees, rotations, radians, encoder counts; seconds or milliseconds) —
the library converts. No STEP/DIR timing, no microstep configuration.
Quick start (Arduino / ESP32)
Install the Servomotor library by Gearotons from the Arduino Library Manager, or fromArduino_library/. Wire the board's UART to an RS-485 transceiver, then:
#include <Servomotor.h>

void setup() {
  Servomotor motor('X', Serial1);                  // alias 'X'; the port opens on first use
  motor.setPositionUnit(PositionUnit::SHAFT_ROTATIONS);
  motor.setTimeUnit(TimeUnit::SECONDS);
  motor.enableMosfets();
  motor.trapezoidMove(2.0f, 3.0f);                 // two rotations over three seconds
  delay(4000);
  Serial.println(motor.getPosition());             // where it actually is, from the encoder
}
void loop() {}
That is a trimmed Arduino_library/example_one_move.cpp
(the full file adds the ESP32 RS-485 pin definitions).
Quick start (talk to it)
uvx --from servomotor-mcp servomotor-mcp # runs with a simulated motor if no hardware is attached
Add it to Claude Desktop or run claude mcp add gearotons-motor -- uvx --from servomotor-mcp servomotor-mcp,
then ask: "Find my motors, then move the one on the bench to 90 degrees and tell me where it ended up."
Details and the full tool list: Gearotons/servomotor-mcp.
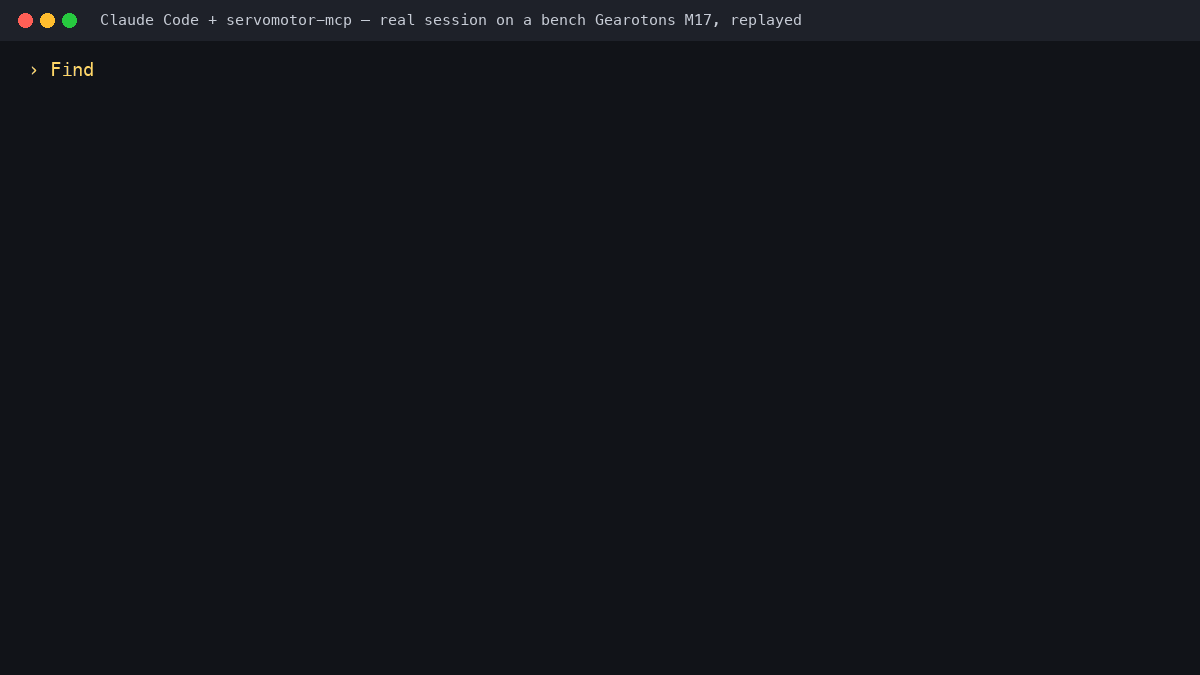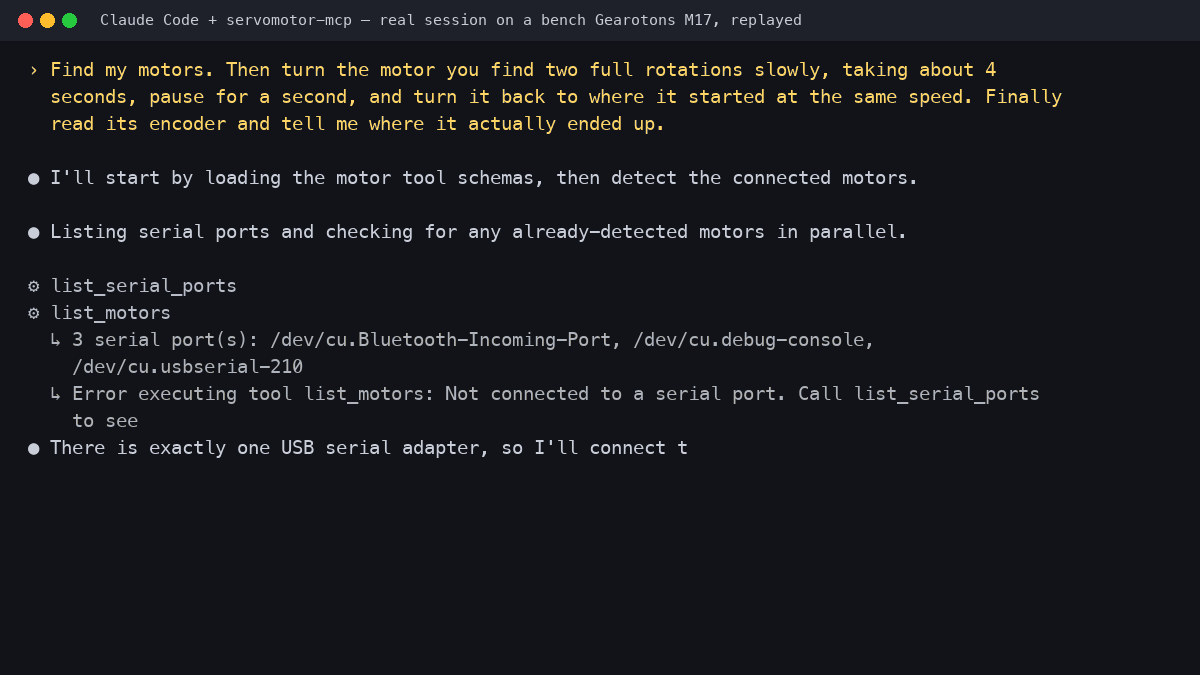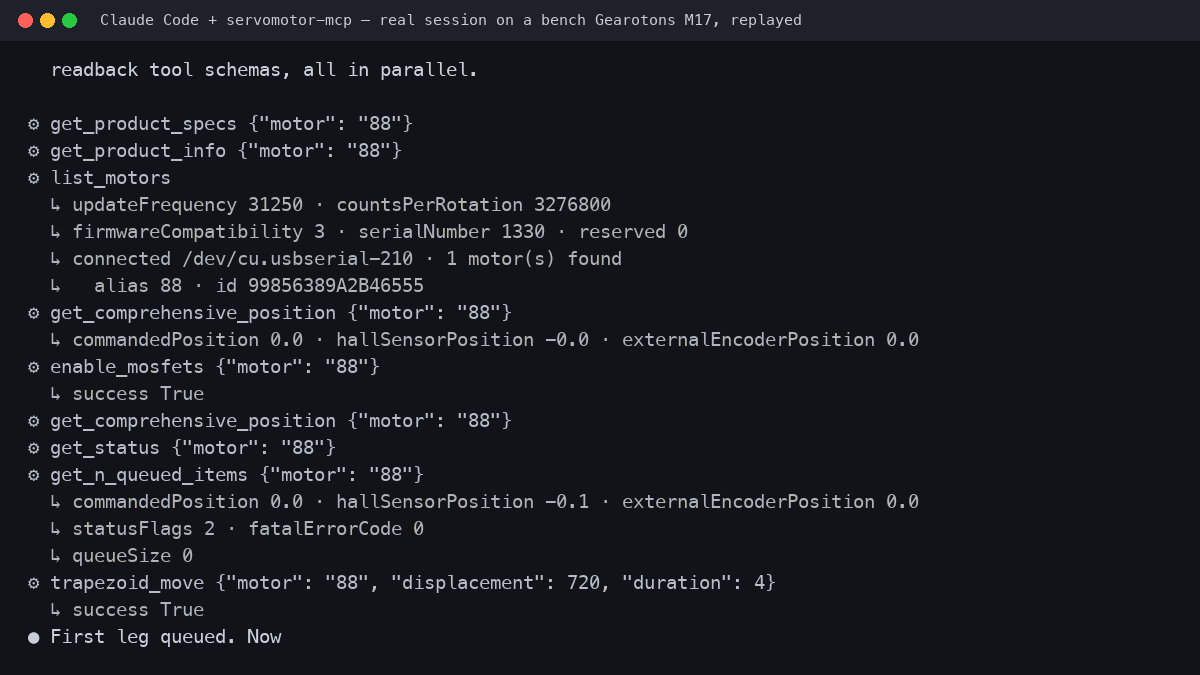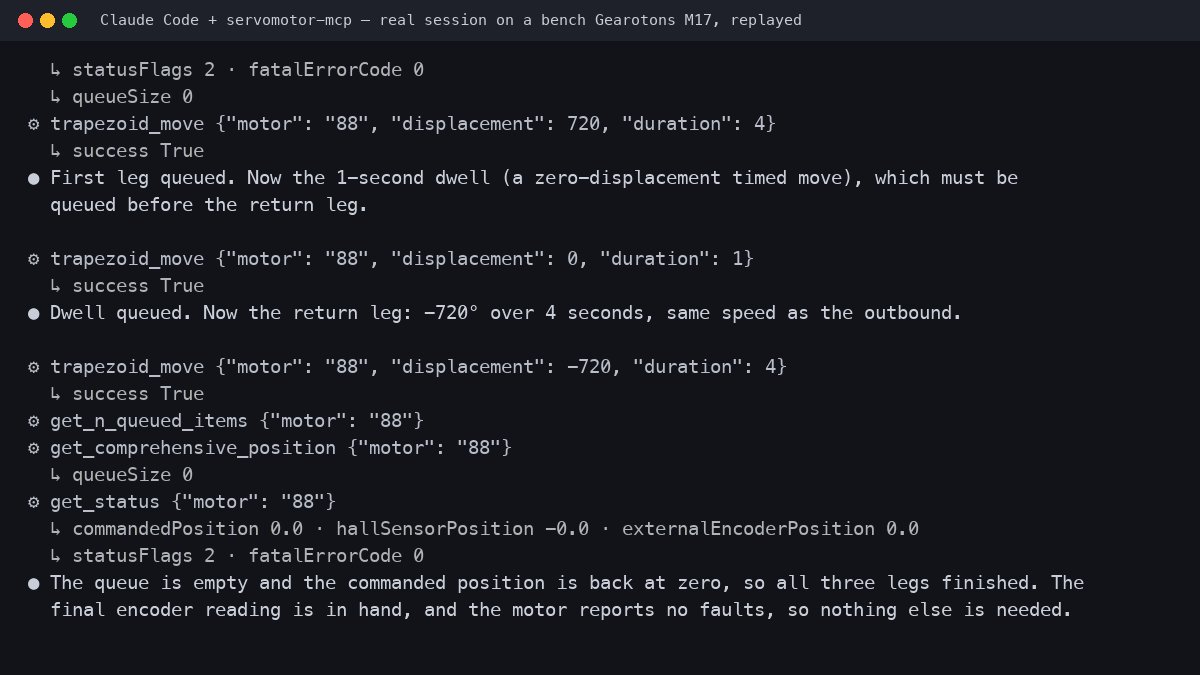
▶ 50-second video: the real motor and this session side by side (recorded 2026-09-09 on a bench M17).
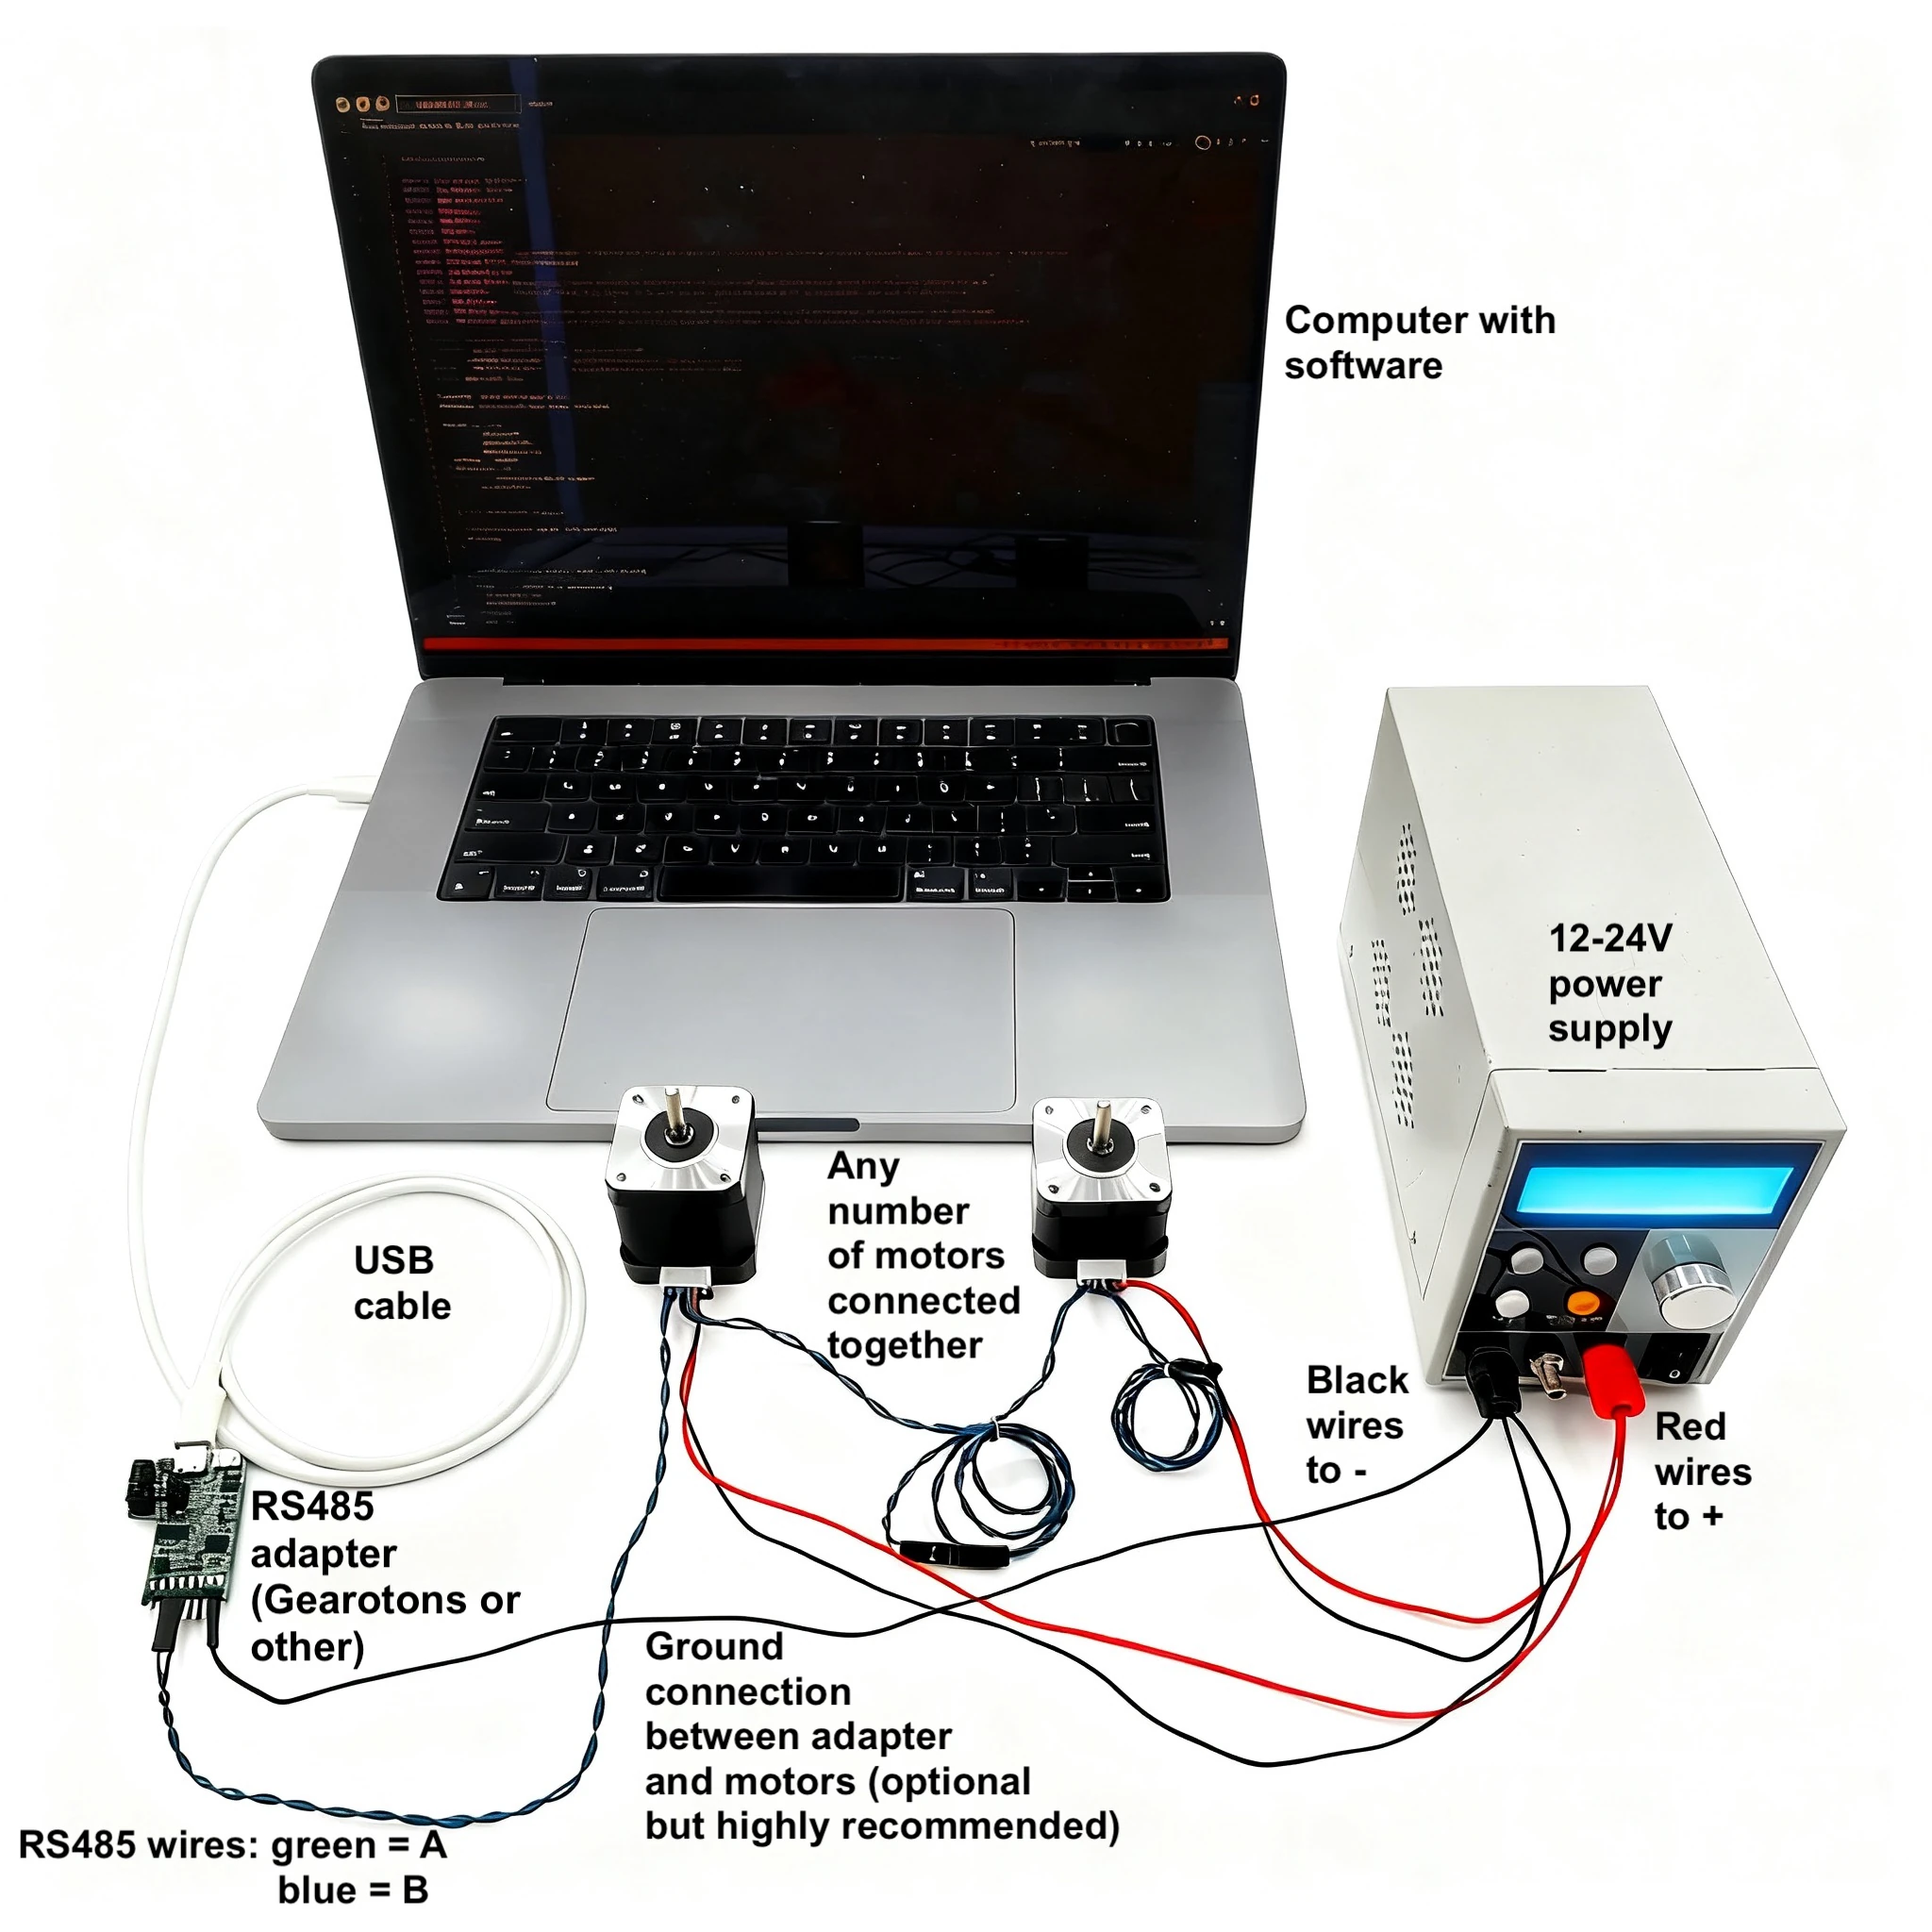
What is in this repository
| Folder | Contents |
|---|---|
firmware/ |
Motor firmware (STM32G0), plus bootloader_STM32G030/ and bootloader_STM32G031/ |
PCB/ |
Schematics, board layouts and 3D (STEP) models of the controller board |
python_programs/ |
The servomotor Python library source, examples, test and characterisation scripts |
Arduino_library/ |
The Arduino/ESP32 C++ library and examples |
API_documentation/ |
Generated Python and Arduino API references (Markdown and PDF) |
servomotor_datasheets/ |
Datasheet sources and PDFs (EN, DE, ES, FR, IT, PT), dimension drawings |
production_test_system/, motor_tests/ |
How we test motors before they ship |
marketting_page/ |
Source of the gearotons.com product page |
The command set is data-driven: every firmware command is defined once inmotor_commands.json and the Python library, the Arduino library and the MCP server are generated
from it, so they always agree.
Firmware 0.16.0.0
This backward-compatible M17 release adds Get PID constants (command 48).
It returns the configured raw P, I and D values without changing controller or
motion state. With the updated Python bindings in this repository:
p, i, d = m.get_pid_constants()
The release image targets M17 hardware 1.5, software compatibility code 3.
See the release notes
for the wire contract, upgrade/rollback commands, client requirements and test evidence.
Where the M17 is not the right tool
Direct-drive torque tops out at 0.65 N·m (gear it or go up a frame size for more), it is IP20 and
indoor-only, and it is not a STEP/DIR drop-in for an existing 3D-printer board — it wants a serial
bus and a host that sends it moves. We would rather you know that before you buy.
Community and support
Questions and builds: GitHub Discussions ·
email [email protected]. Issues and pull requests welcome — the whole
stack is here to be read, modified and improved.
Built and assembled by Gearotons in Shenzhen. MIT license — see LICENSE.
Reviews (0)
Sign in to leave a review.
Leave a reviewNo results found